
ROBROS Unveils Full-Body Teleoperation Video of Its Humanoid Robot [Robo Insight]
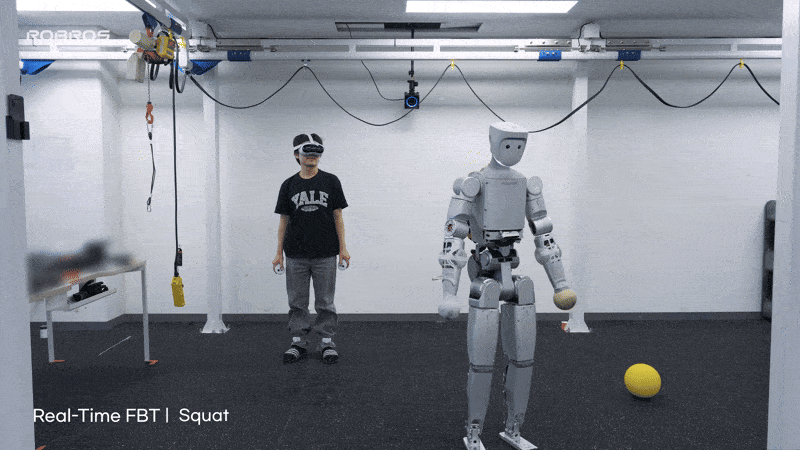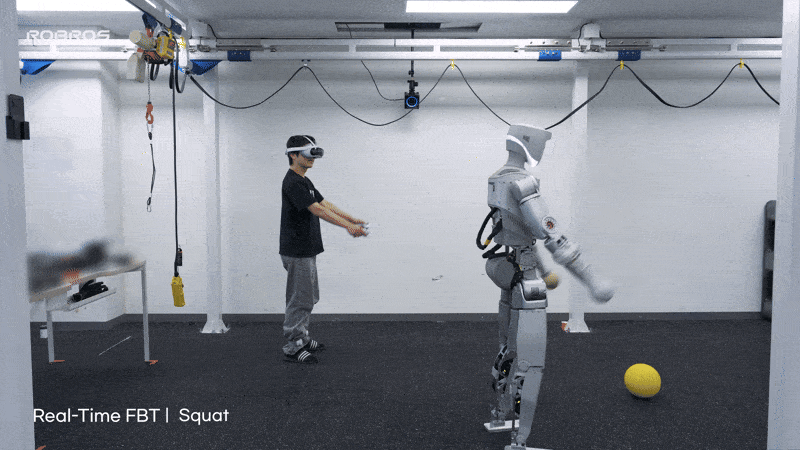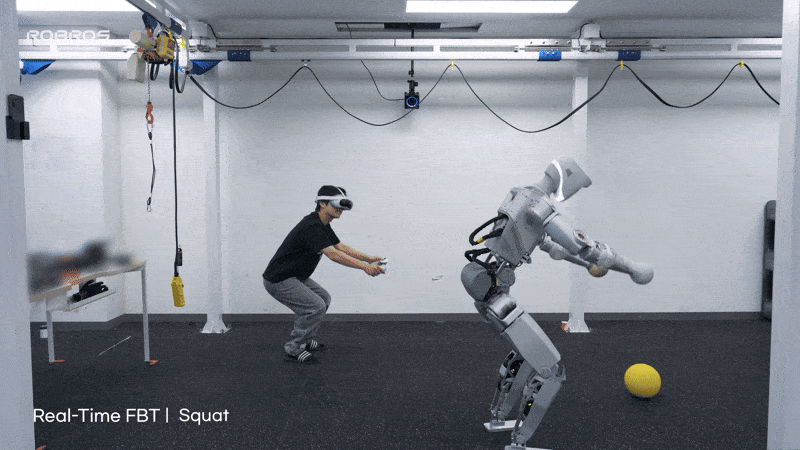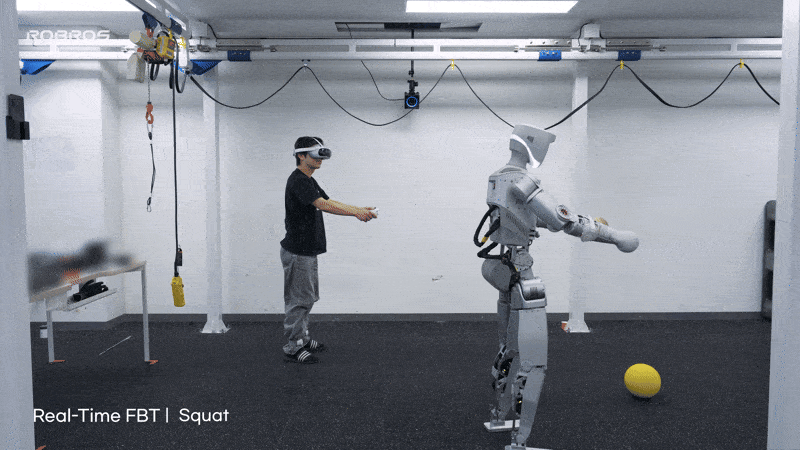
ROBROS announced on the 22nd that it has released a video showcasing real-time full-body teleoperation technology for its bipedal humanoid robot "IGRIS-C."
Previously, ROBROS had demonstrated teleoperation technology that reproduced human movements in real time, centered on IGRIS-C's upper body. This time, the company expanded the scope of teleoperation to the lower body as well, linking the operator's movements to the robot's whole-body motion.
In the released video, IGRIS-C moves its upper and lower body simultaneously in accordance with the operator's movements, demonstrating actions such as punching a sandbag and kicking a ball. The key to real-time full-body teleoperation is that rather than replaying predetermined motions, the operator can assess the surrounding situation firsthand and integrally control the humanoid robot's locomotion and tasks in real time. Whereas upper-body-centered teleoperation was mainly used for tasks involving the arms from a fixed position, full-body teleoperation can also handle situations that combine locomotion and work—such as moving the robot and changing its posture while manipulating objects with both arms. ROBROS plans to expand the scope of the technology's application to various industrial environments going forward, in line with customer requirements.
A ROBROS official said of the real-time full-body teleoperation technology, "In that it allows a human to assess a situation and connect the robot's locomotion and manipulation in real time, it is an important technology for applying humanoids to industrial sites where it is difficult to define every situation in advance."