
Dev Center
Dev Center
Overview & Components
1. Product Overview
IGRIS-C is a humanoid robot with a height of 154 cm and a gender-neutral form factor, developed for use in a wide range of experimental and practical environments.
The rear of the robot features a Power Button (left) and an EMO (Emergency Machine Off) switch (right).
A Head Indicator (LED) is mounted beneath the robot’s head for status indication.

2. Key Specifications
Item | Specification |
|---|---|
Model | IGRIS-C |
Dimensions | 1540 × 440 × 300 mm |
Height | 154 cm |
Weight | 60 kg |
Total Degrees of Freedom | 53 DoF (Legs 6 DoF ×2, Arms 7 DoF ×2, Waist 3 DoF, Neck 2 DoF, Hands 11 DoF ×2) |
Hand Degrees of Freedom | 11 DoF (6 Active DoF + 5 Passive DoF) |
Number of Fingers | 5 |
Maximum Joint Torque | 150 Nm |
Maximum Payload | 6 kg (using both arms) |
Battery | 17,000 mAh / 48 V |
Computing System | Intel Core i7 |
3. Standard Package Contents
Packaging Box
Humanoid Robot (IGRIS-C)
Power Supply Unit
Battery
Battery Charger
Wireless Emergency Stop Switch (Battery: 23A, 12 V)
Master Arm
Application Software
*Hoist not included. Sold separately.

4. Sensors
IGRIS-C carries three camera types and an IMU. Camera images arrive on the topics listed on the Camera page; the operating settings (resolution, frame rate) are changed in Web Viewer › Config › camera config.
Sensor | Model | Location | Use |
|---|---|---|---|
Eye stereo camera | GXIVISION LSM22100 (module LS1M02) | Head (eyes) | Left/right RGB stereo images |
Head RGBD camera | Intel RealSense D435i | Head | Color, depth and IR images; built-in 6-DoF IMU |
End-effector camera | Weinan WN-L2112K314LFT-0234 V2 | Both hands | RGB view of the hand workspace (one per hand) |
IMU | MicroStrain 3DM-CV7-AR | Torso | Orientation, angular rate, acceleration (no magnetometer) |
Eye stereo camera — GXIVISION LSM22100
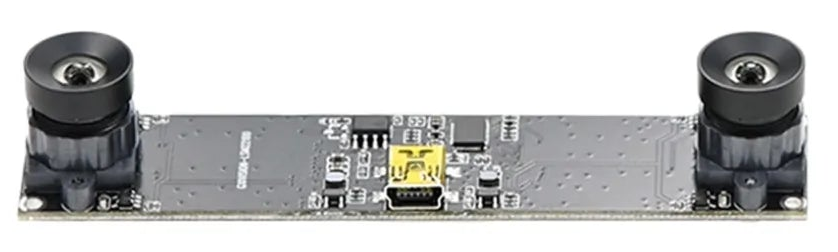
Item | Specification |
|---|---|
Connection | USB 2.0 (UVC), USB bus power 5 V |
Image sensor | 2 × SuperPix SP1405, 1/4″, 1280 × 720 per sensor, 3.0 µm pixel |
Shutter | Electronic rolling shutter |
Output format | MJPEG, YUY2 |
Mode | Format | Resolution | FPS |
|---|---|---|---|
Binocular | MJPEG | 2560 × 720 | 30 |
Binocular | MJPEG | 1280 × 480 | 30 |
Binocular | YUY2 | 1280 × 720 | 5 |
Binocular | YUY2 | 1280 × 480 | 15 |
Monocular | MJPEG | 1280 × 720 | 30 |
Monocular | MJPEG | 640 × 480 | 30 |
Monocular | YUY2 | 1280 × 720 | 10 |
Monocular | YUY2 | 640 × 480 | 30 |
Head RGBD camera — Intel RealSense D435i
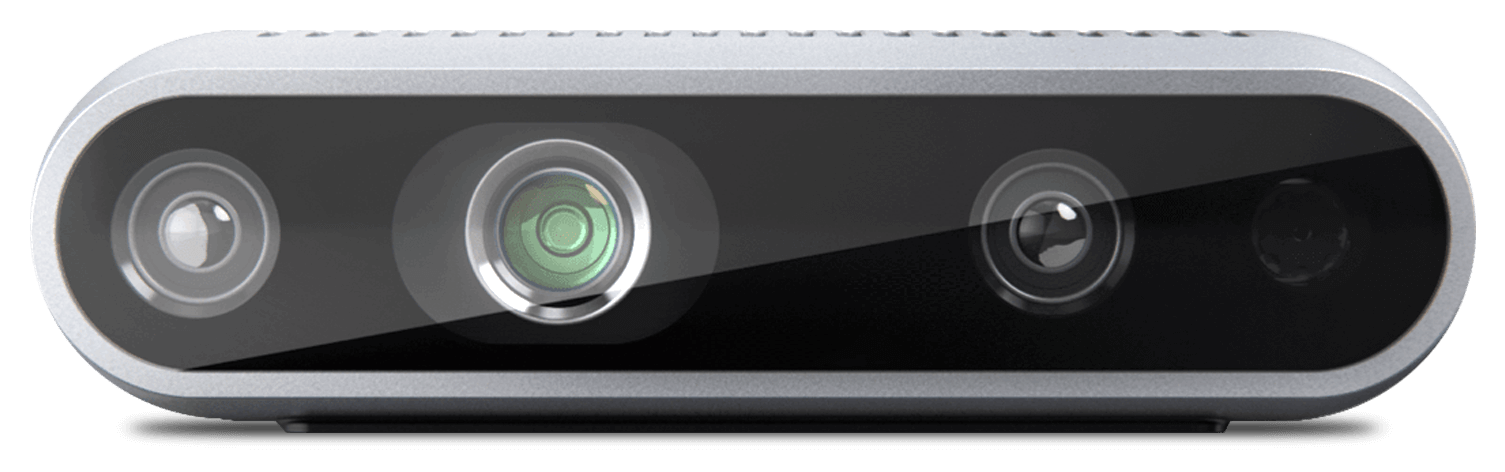
Item | Specification |
|---|---|
Connection | USB-C 3.1 Gen 1 |
Shutter | Depth (stereo IR): global shutter / RGB: rolling shutter |
IMU | Built-in 6-DoF IMU |
Stream | Max resolution | Max FPS | FOV |
|---|---|---|---|
Depth | 1280 × 720 | 90 | 87° × 58° |
RGB | 1920 × 1080 | 30 | 69° × 42° |
End-effector camera — Weinan WN-L2112K314LFT-0234 V2
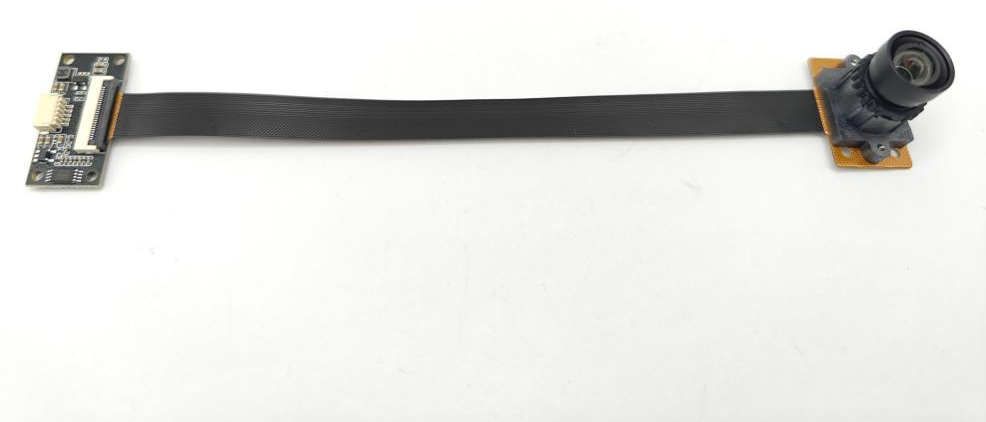
Item | Specification |
|---|---|
Connection | USB 2.0, 5 V (5-pin 1.0 mm, SM05B-SRSS-TB) |
Image sensor | onsemi AR0234, 1/2.6″, 1920 × 1200, 3.0 µm pixel |
Shutter | Global shutter |
Output format | MJPEG, YUV2 |
Resolution | MJPEG FPS | YUV2 FPS |
|---|---|---|
1920 × 1200 (raw) | 90 / 30 / 20 / 10 / 5 | 2 |
1920 × 1080 (center crop) | 90 / 30 / 20 / 10 / 5 | 5 |
1280 × 720 (center crop) | 160 / 90 / 30 / 20 / 10 / 5 | 10 |
640 × 480 (center crop) | 230 / 90 / 30 / 20 / 10 / 5 | 30 |
320 × 240 (center crop) | 420 / 90 / 30 / 20 / 10 / 5 | 60 |
※ The values are the camera-module specifications. What the robot actually streams follows the camera config defaults (see the Camera page).
Overview & Components
1. Product Overview
IGRIS-C is a humanoid robot with a height of 154 cm and a gender-neutral form factor, developed for use in a wide range of experimental and practical environments.
The rear of the robot features a Power Button (left) and an EMO (Emergency Machine Off) switch (right).
A Head Indicator (LED) is mounted beneath the robot’s head for status indication.
2. Key Specifications
Item | Specification |
|---|---|
Model | IGRIS-C |
Dimensions | 1540 × 440 × 300 mm |
Height | 154 cm |
Weight | 60 kg |
Total Degrees of Freedom | 53 DoF (Legs 6 DoF ×2, Arms 7 DoF ×2, Waist 3 DoF, Neck 2 DoF, Hands 11 DoF ×2) |
Hand Degrees of Freedom | 11 DoF (6 Active DoF + 5 Passive DoF) |
Number of Fingers | 5 |
Maximum Joint Torque | 150 Nm |
Maximum Payload | 6 kg (using both arms) |
Battery | 17,000 mAh / 48 V |
Computing System | Intel Core i7 |
3. Standard Package Contents
Packaging Box
Humanoid Robot (IGRIS-C)
Power Supply Unit
Battery
Battery Charger
Wireless Emergency Stop Switch (Battery: 23A, 12 V)
Master Arm
Application Software
*Hoist not included. Sold separately.
4. Sensors
IGRIS-C carries three camera types and an IMU. Camera images arrive on the topics listed on the Camera page; the operating settings (resolution, frame rate) are changed in Web Viewer › Config › camera config.
Sensor | Model | Location | Use |
|---|---|---|---|
Eye stereo camera | GXIVISION LSM22100 (module LS1M02) | Head (eyes) | Left/right RGB stereo images |
Head RGBD camera | Intel RealSense D435i | Head | Color, depth and IR images; built-in 6-DoF IMU |
End-effector camera | Weinan WN-L2112K314LFT-0234 V2 | Both hands | RGB view of the hand workspace (one per hand) |
IMU | MicroStrain 3DM-CV7-AR | Torso | Orientation, angular rate, acceleration (no magnetometer) |
Eye stereo camera — GXIVISION LSM22100
Item | Specification |
|---|---|
Connection | USB 2.0 (UVC), USB bus power 5 V |
Image sensor | 2 × SuperPix SP1405, 1/4″, 1280 × 720 per sensor, 3.0 µm pixel |
Shutter | Electronic rolling shutter |
Output format | MJPEG, YUY2 |
Mode | Format | Resolution | FPS |
|---|---|---|---|
Binocular | MJPEG | 2560 × 720 | 30 |
Binocular | MJPEG | 1280 × 480 | 30 |
Binocular | YUY2 | 1280 × 720 | 5 |
Binocular | YUY2 | 1280 × 480 | 15 |
Monocular | MJPEG | 1280 × 720 | 30 |
Monocular | MJPEG | 640 × 480 | 30 |
Monocular | YUY2 | 1280 × 720 | 10 |
Monocular | YUY2 | 640 × 480 | 30 |
Head RGBD camera — Intel RealSense D435i
Item | Specification |
|---|---|
Connection | USB-C 3.1 Gen 1 |
Shutter | Depth (stereo IR): global shutter / RGB: rolling shutter |
IMU | Built-in 6-DoF IMU |
Stream | Max resolution | Max FPS | FOV |
|---|---|---|---|
Depth | 1280 × 720 | 90 | 87° × 58° |
RGB | 1920 × 1080 | 30 | 69° × 42° |
End-effector camera — Weinan WN-L2112K314LFT-0234 V2
Item | Specification |
|---|---|
Connection | USB 2.0, 5 V (5-pin 1.0 mm, SM05B-SRSS-TB) |
Image sensor | onsemi AR0234, 1/2.6″, 1920 × 1200, 3.0 µm pixel |
Shutter | Global shutter |
Output format | MJPEG, YUV2 |
Resolution | MJPEG FPS | YUV2 FPS |
|---|---|---|
1920 × 1200 (raw) | 90 / 30 / 20 / 10 / 5 | 2 |
1920 × 1080 (center crop) | 90 / 30 / 20 / 10 / 5 | 5 |
1280 × 720 (center crop) | 160 / 90 / 30 / 20 / 10 / 5 | 10 |
640 × 480 (center crop) | 230 / 90 / 30 / 20 / 10 / 5 | 30 |
320 × 240 (center crop) | 420 / 90 / 30 / 20 / 10 / 5 | 60 |
※ The values are the camera-module specifications. What the robot actually streams follows the camera config defaults (see the Camera page).