
Dev Center
Dev Center
Specs (DoF)
Hardware variants — From 2.1.1, the wrist and the ankle each come in two variants, v1 and v2. The wrist range of motion differs by variant. Check the robot’s variant in Web Viewer › Config under
description.common.wrist_version/description.common.ankle_version. Both values must match the actual hardware. Ankle v2 is a reinforced foot and has the same range of motion as v1.
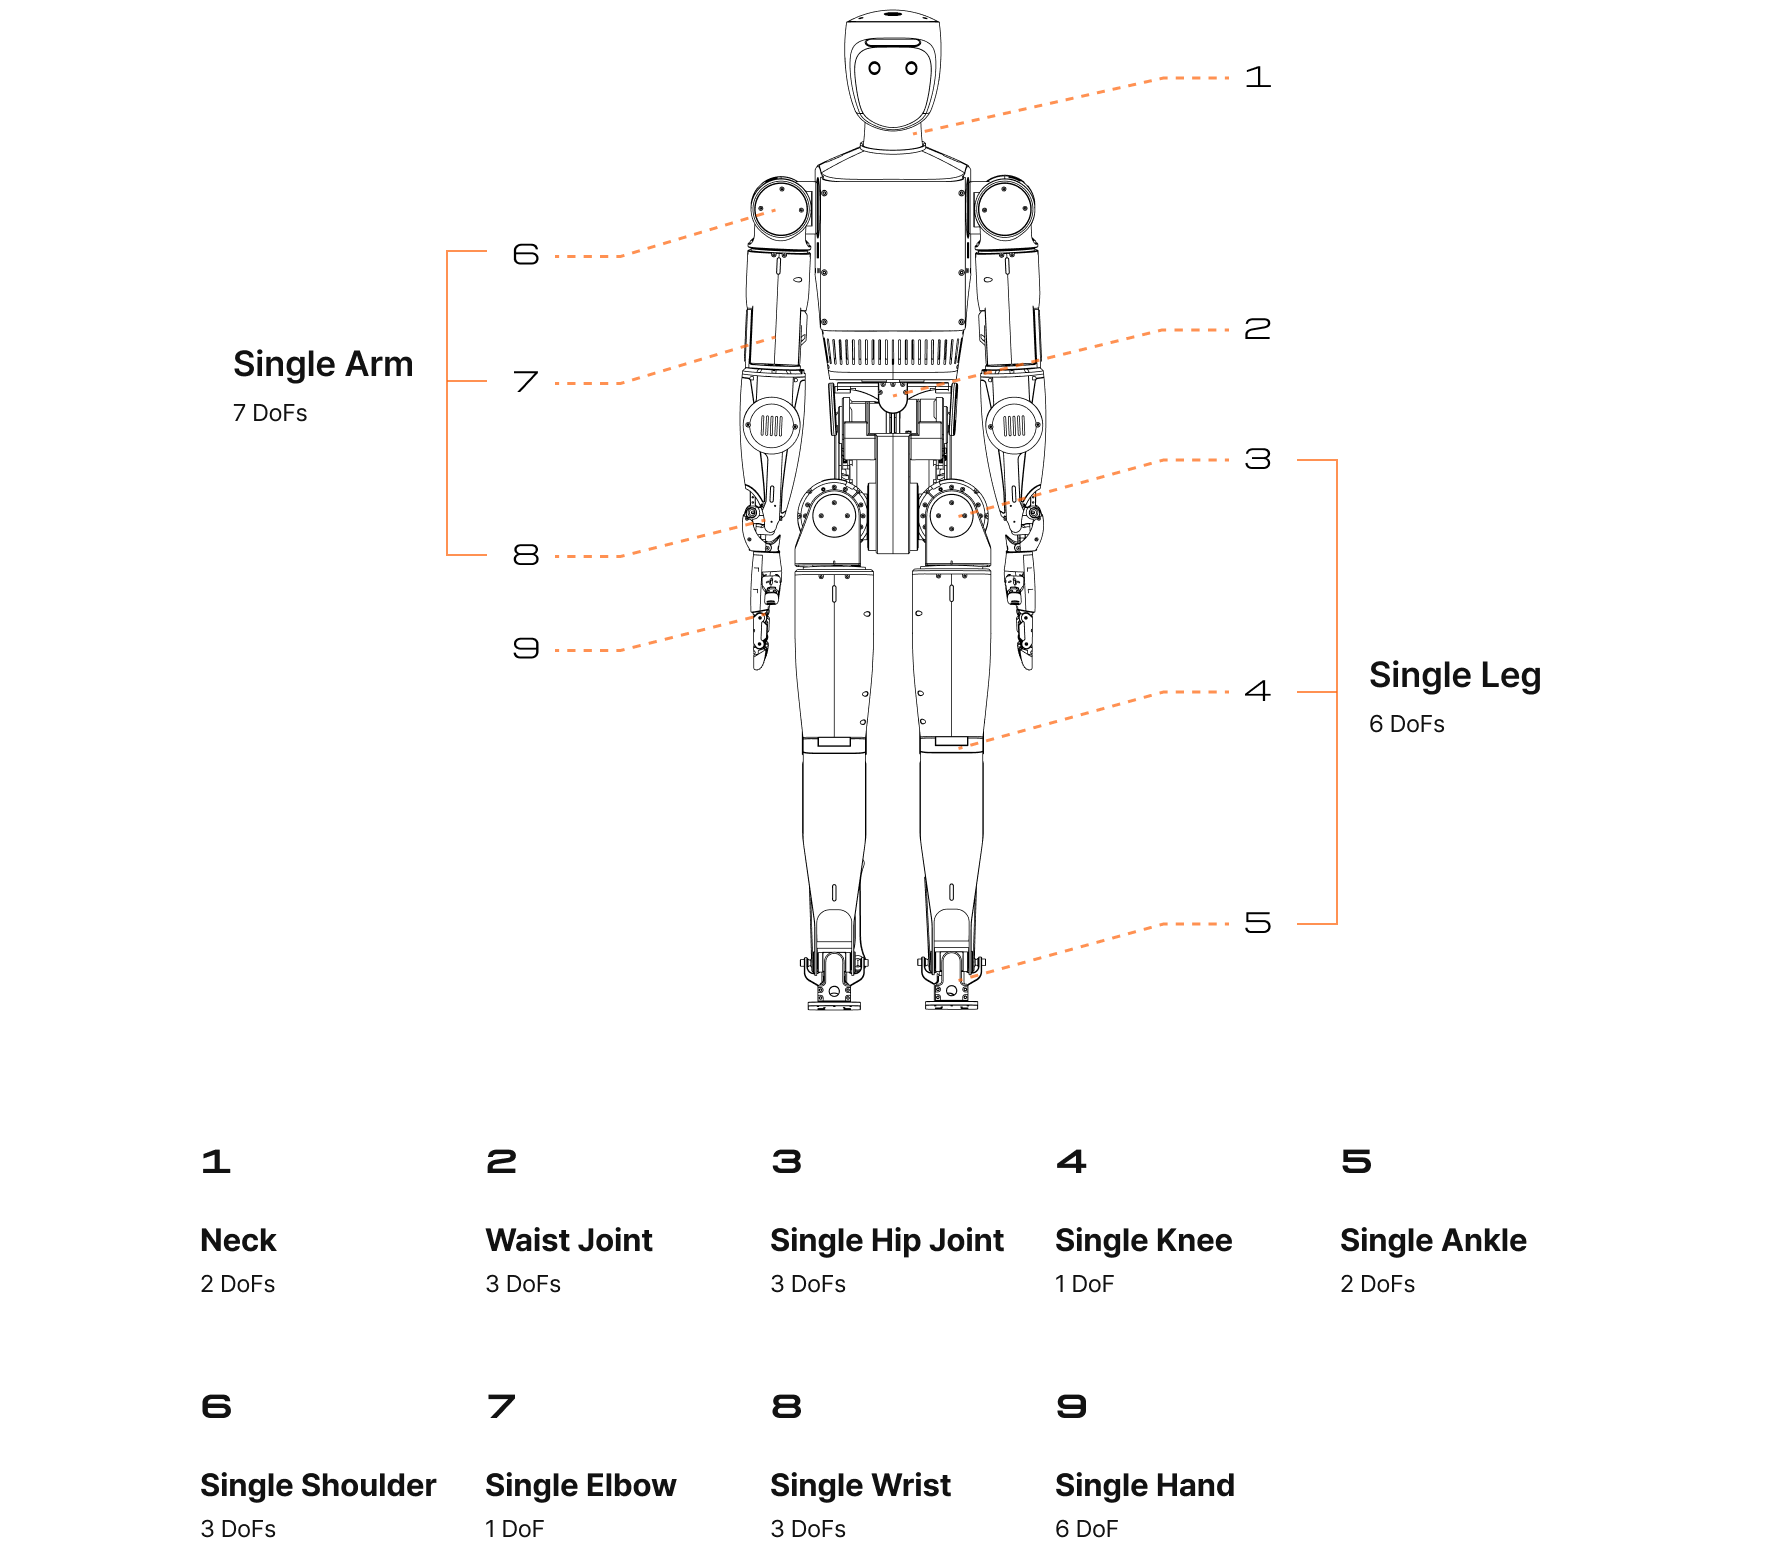
1. Degree of Freedom
Total 31 DoFs (excluding hands): neck 2, waist 3, legs 6 × 2 (hip 3, knee 1, ankle 2), arms 7 × 2 (shoulder 3, elbow 1, wrist 3)
The waist, ankles, and wrists use parallel-link mechanisms, so their roll / pitch axes are mechanically coupled. Each listed range applies when the other coupled axis is at 0°.
2. Axis Convention
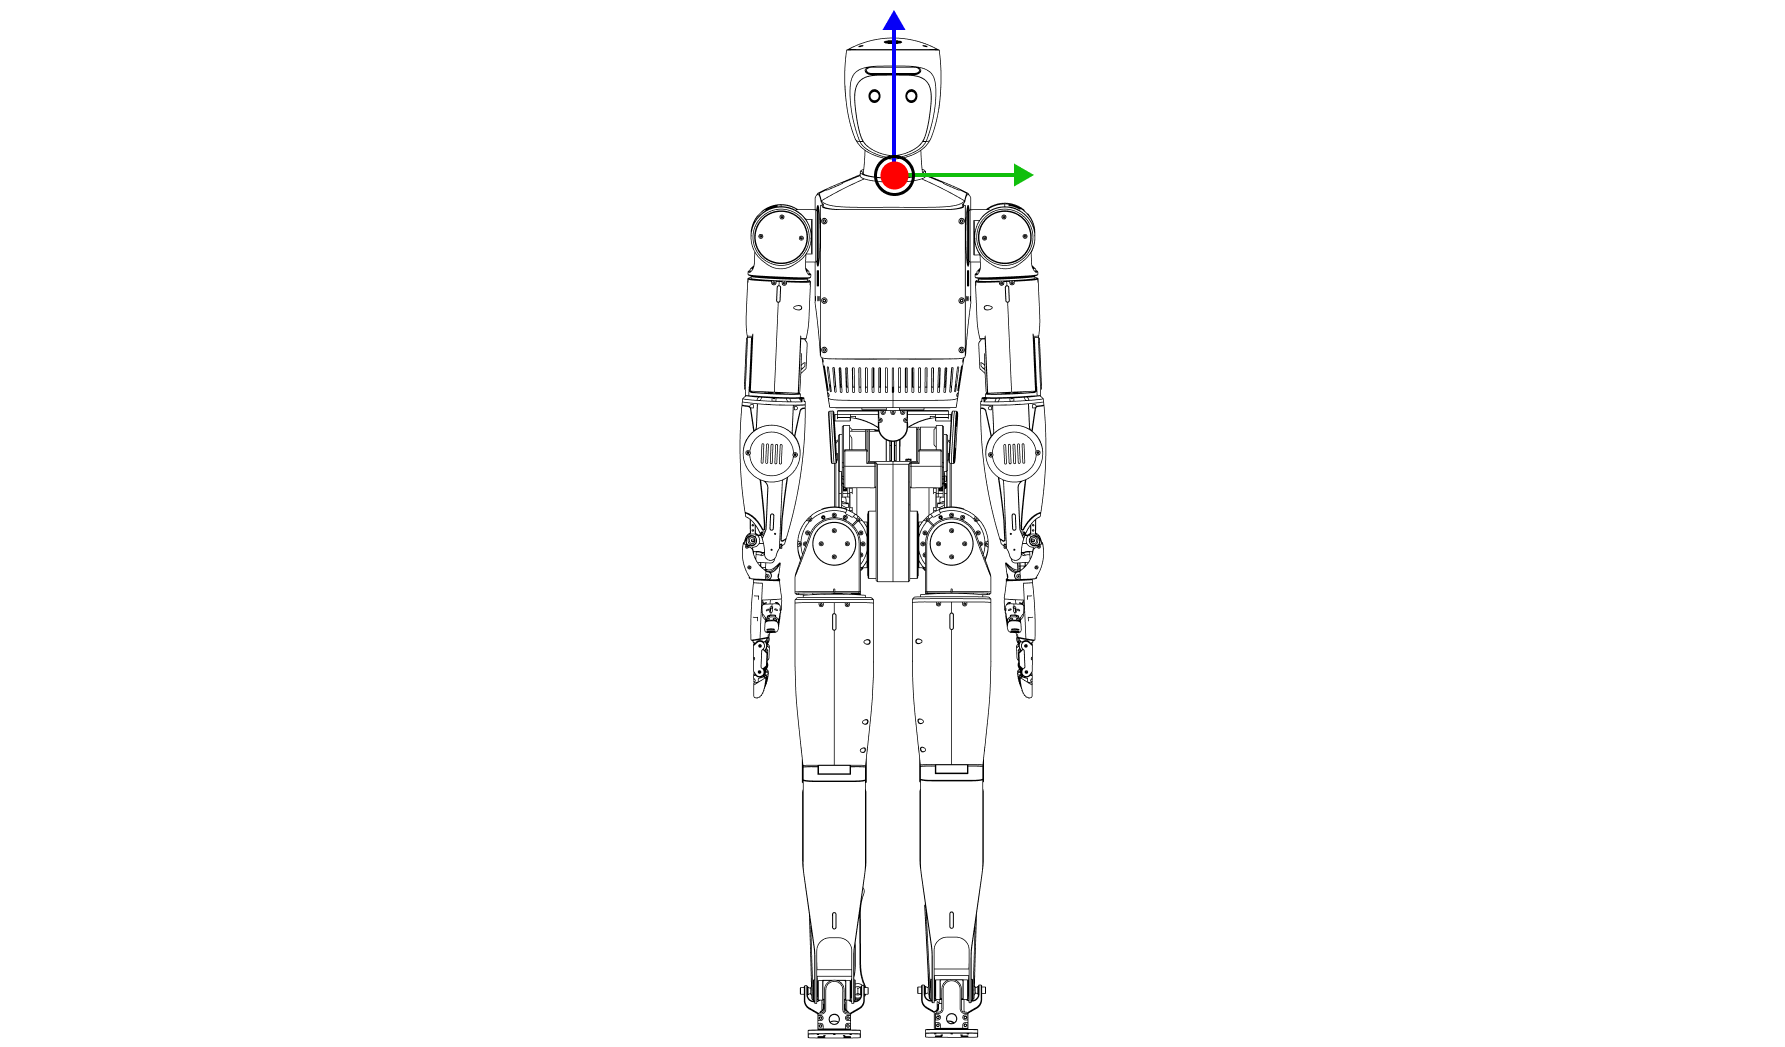
All joint axes are given with respect to the following fixed axes in the upright standing pose.
Front = X, Left = Y, Top = Z
3. Joint Range of Motion
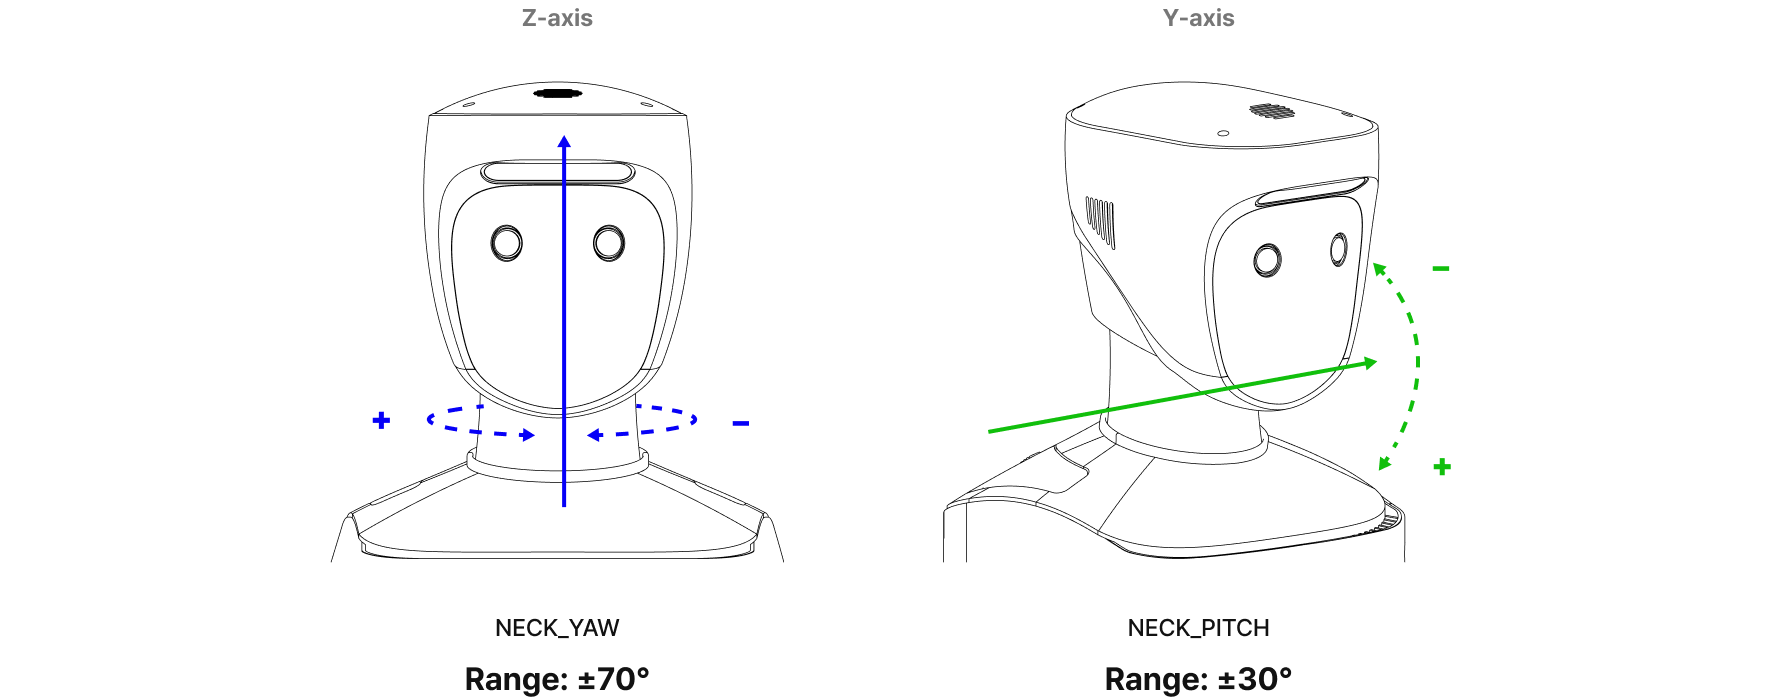
NECK
JOINT | AXIS | MIN (°) | MAX (°) |
|---|---|---|---|
NECK_YAW | Z | -70 | 70 |
NECK_PITCH | Y | -30 | 30 |
WAIST
JOINT | AXIS | MIN (°) | MAX (°) |
|---|---|---|---|
WAIST_YAW | Z | -90 | 90 |
WAIST_ROLL | X | -18 | 18 |
WAIST_PITCH | Y | -50 | 16.5 |
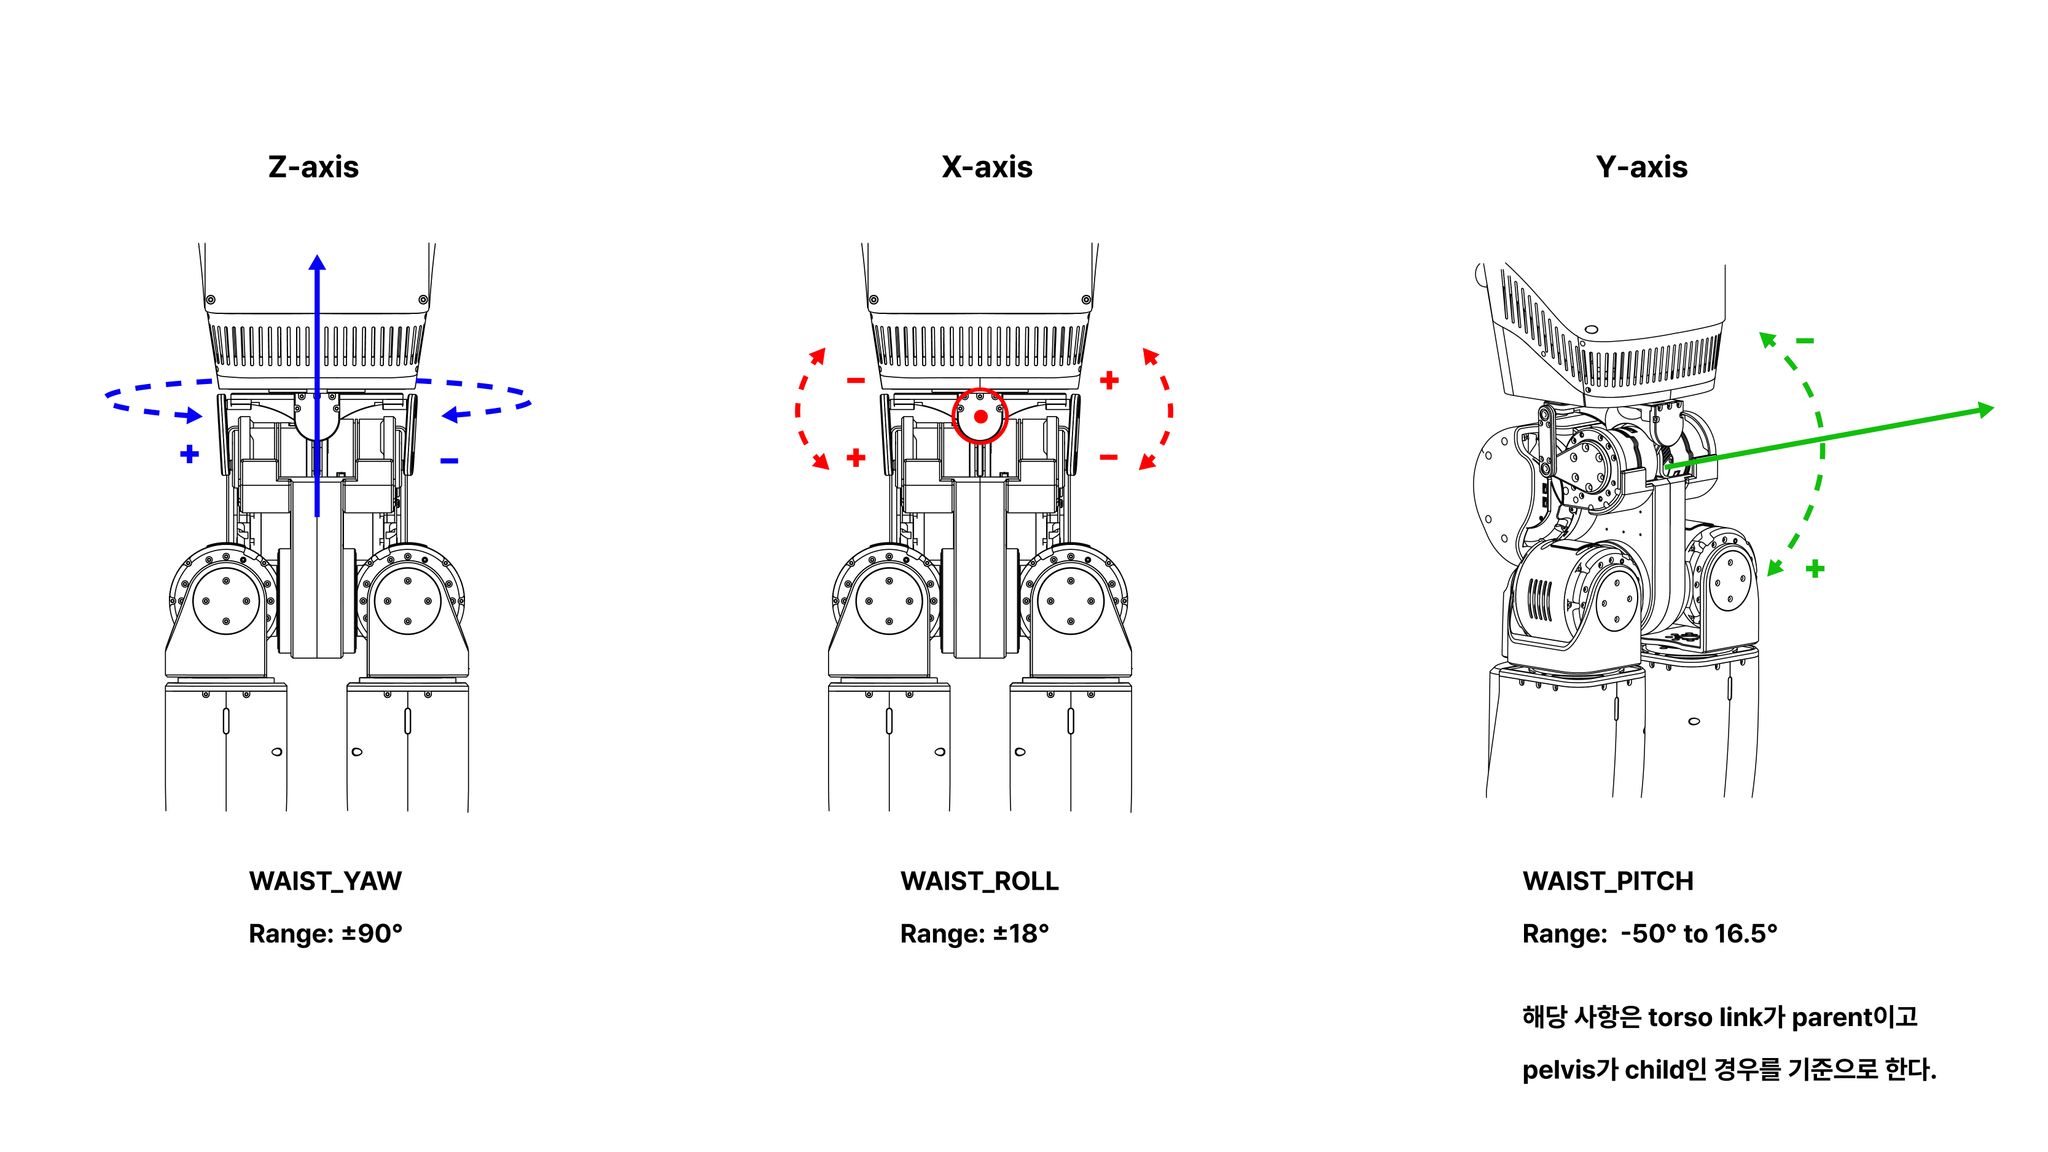
LEFT LEG
JOINT | AXIS | MIN (°) | MAX (°) |
|---|---|---|---|
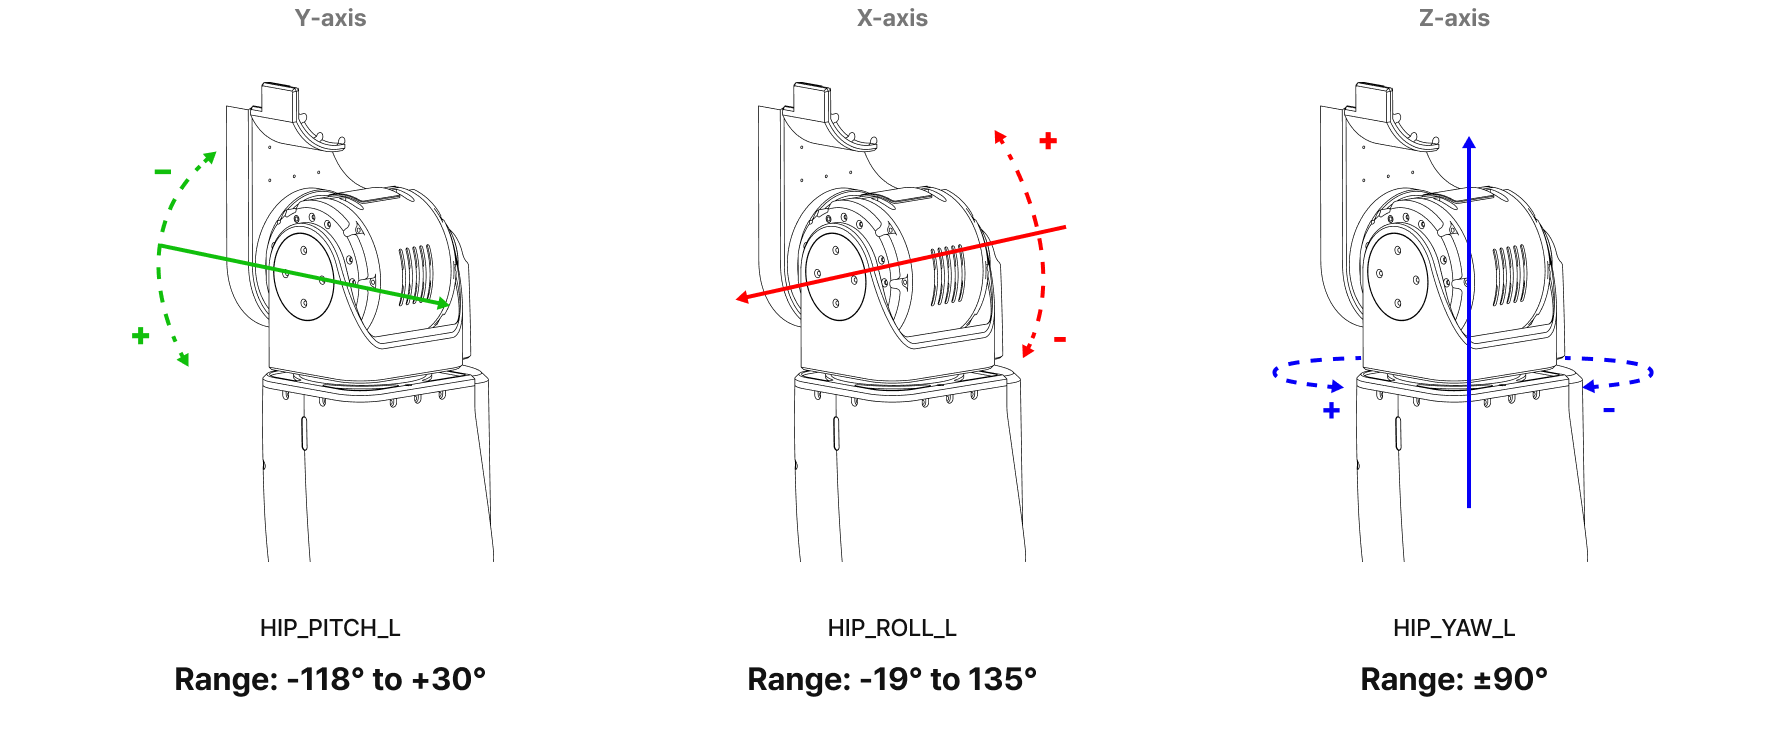
HIP_PITCH_L | Y | -118 | 30 |
HIP_ROLL_L | X | -19 | 135 |
HIP_YAW_L | Z | -90 | 90 |
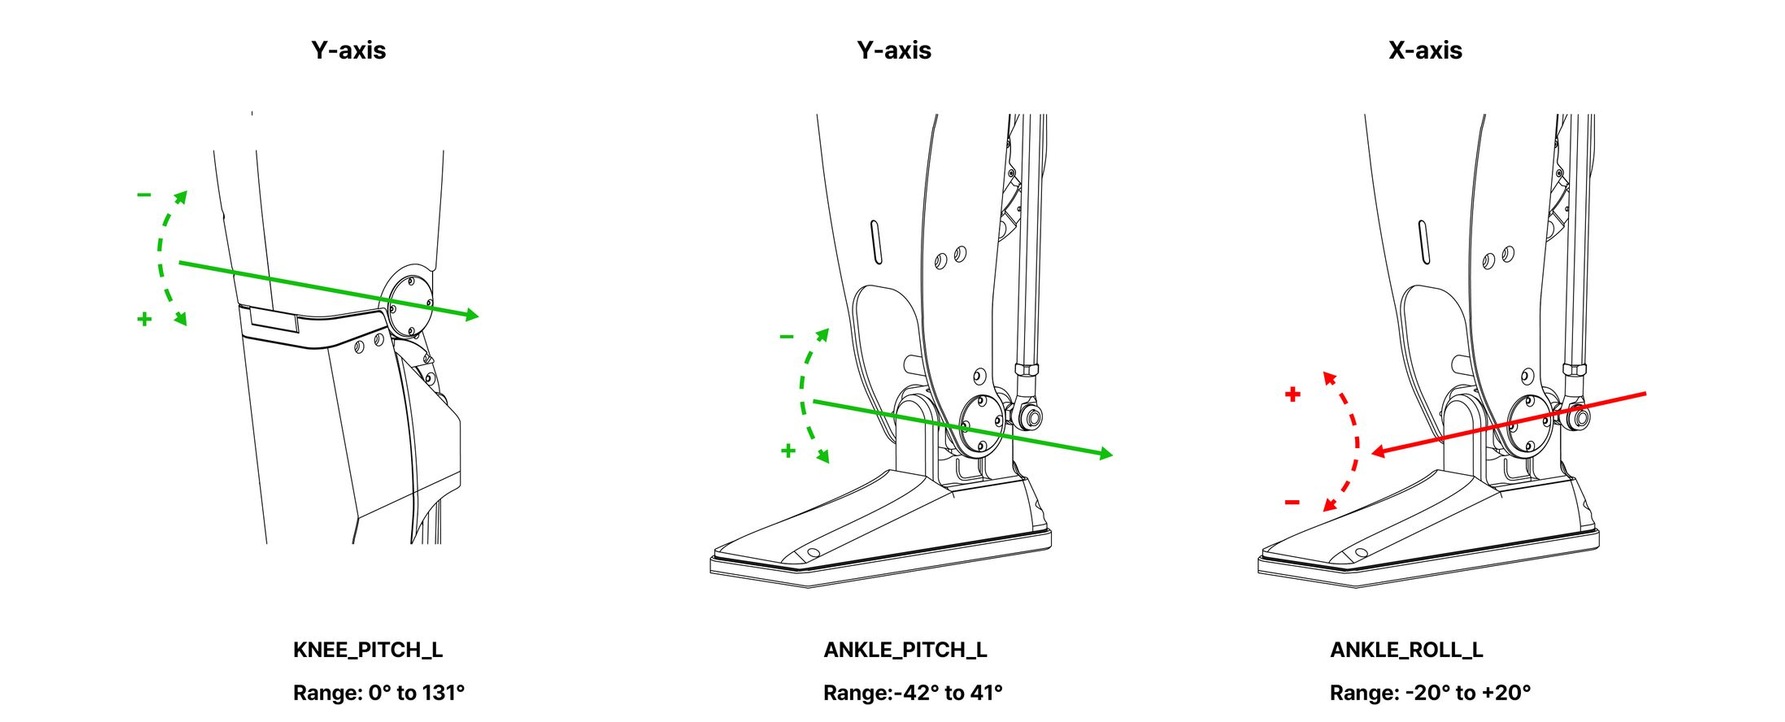
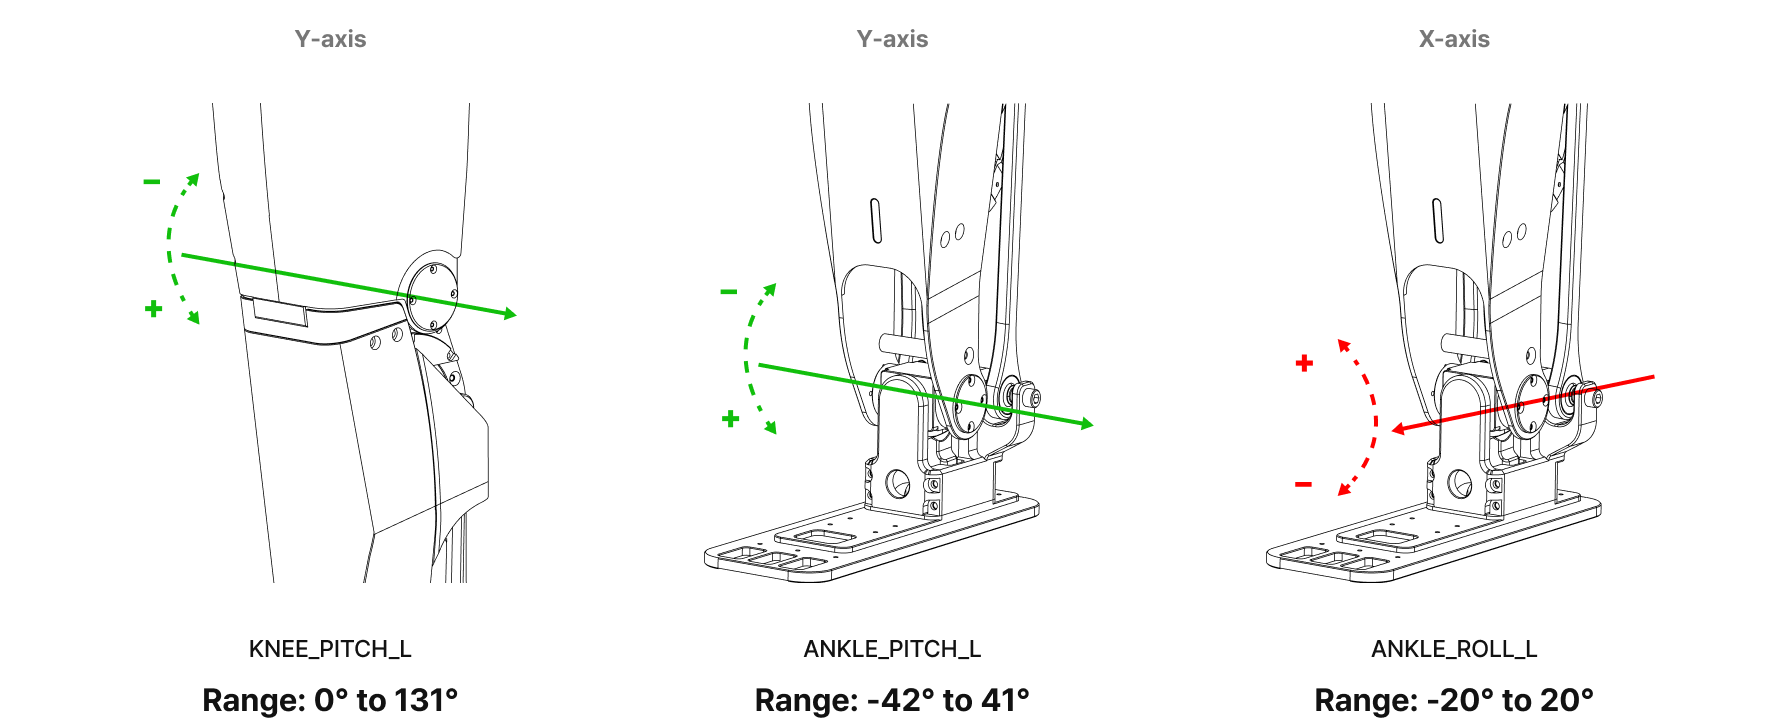
KNEE_PITCH_L | Y | 0 | 131 |
ANKLE_PITCH_L | Y | -42 | 41 |
ANKLE_ROLL_L | X | -20 | 20 |
Hip
Ankle v1 | Ankle v2 |
|---|---|
 |  |
RIGHT LEG
JOINT | AXIS | MIN (°) | MAX (°) |
|---|---|---|---|
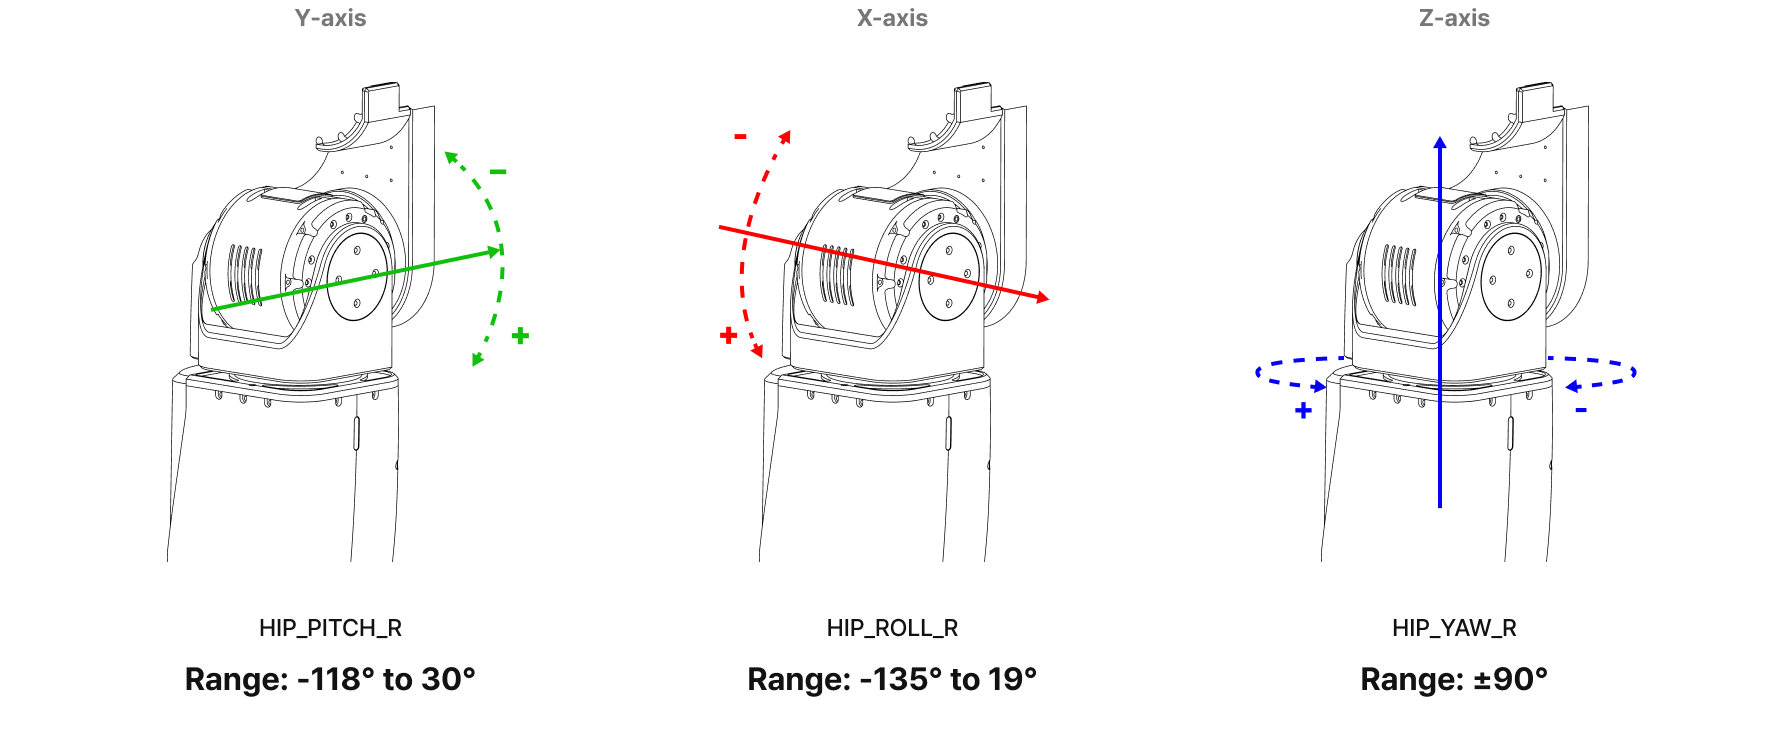
HIP_PITCH_R | Y | -118 | 30 |
HIP_ROLL_R | X | -135 | 19 |
HIP_YAW_R | Z | -90 | 90 |
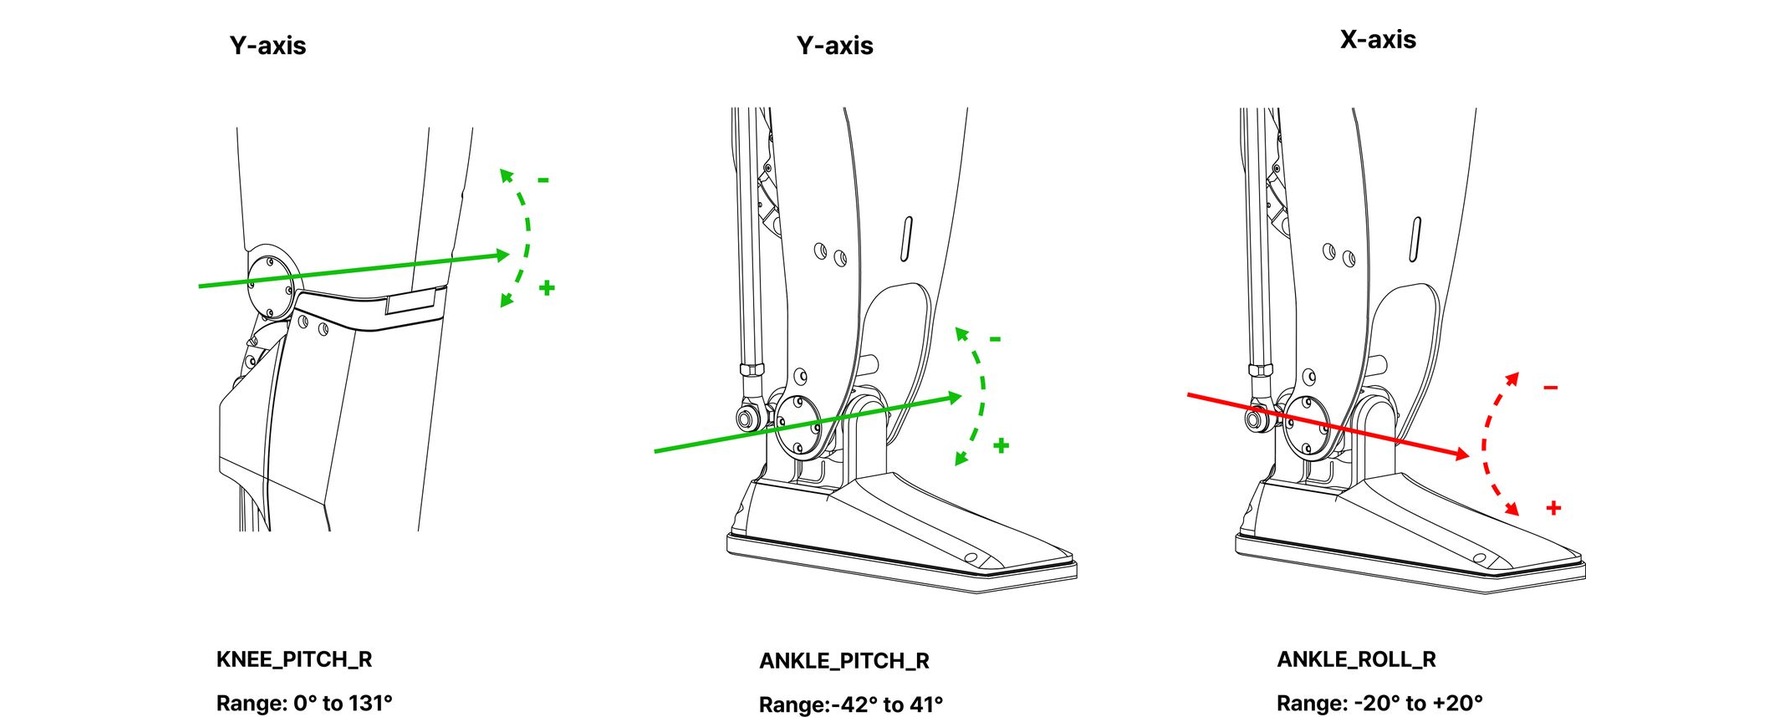
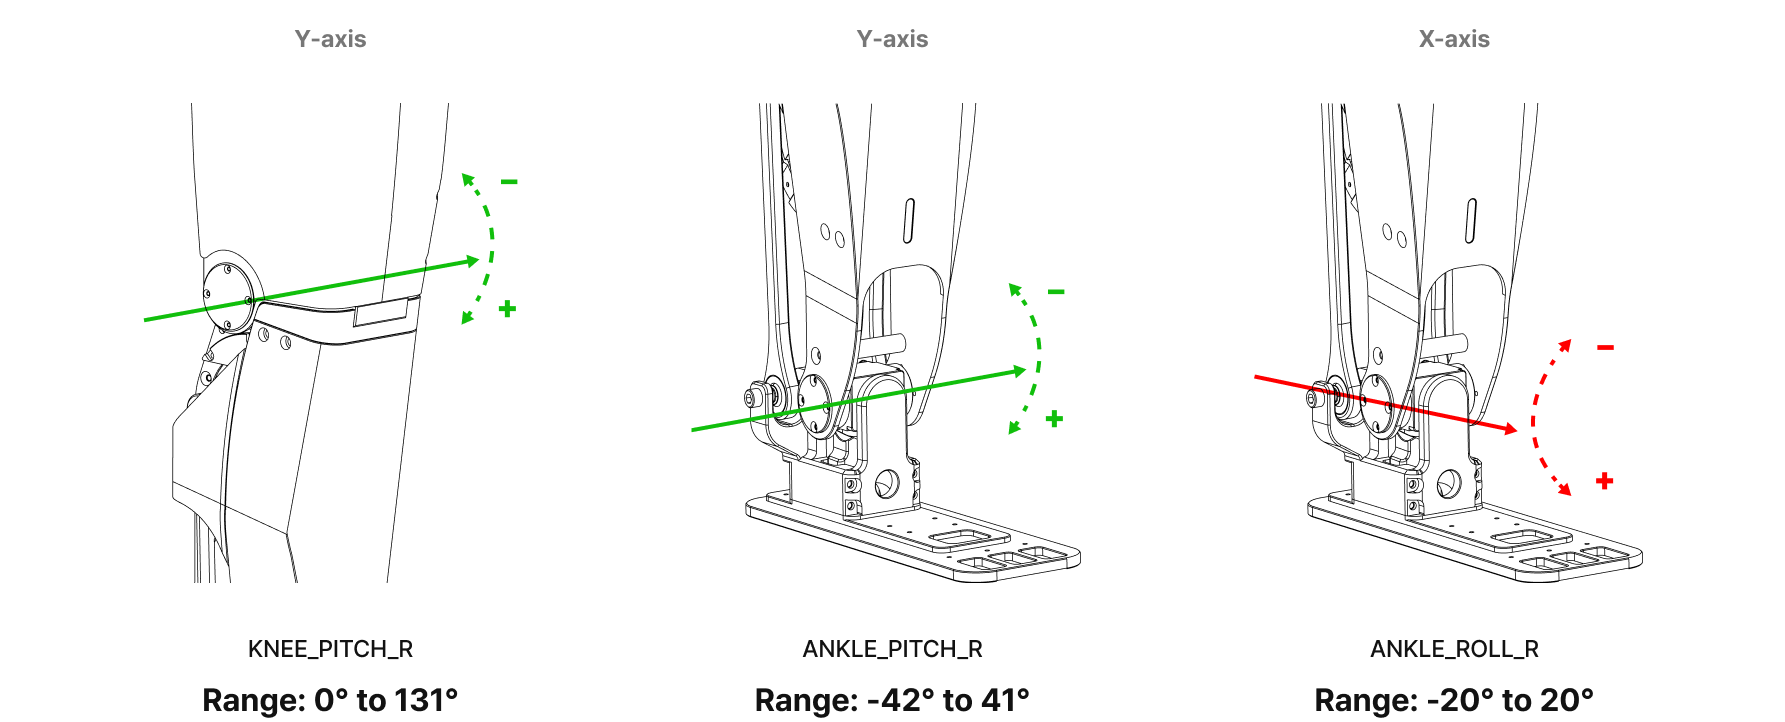
KNEE_PITCH_R | Y | 0 | 131 |
ANKLE_PITCH_R | Y | -42 | 41 |
ANKLE_ROLL_R | X | -20 | 20 |
Hip
Ankle v1 | Ankle v2 |
|---|---|
 |  |
LEFT ARM
JOINT | AXIS | MIN (°) | MAX (°) |
|---|---|---|---|
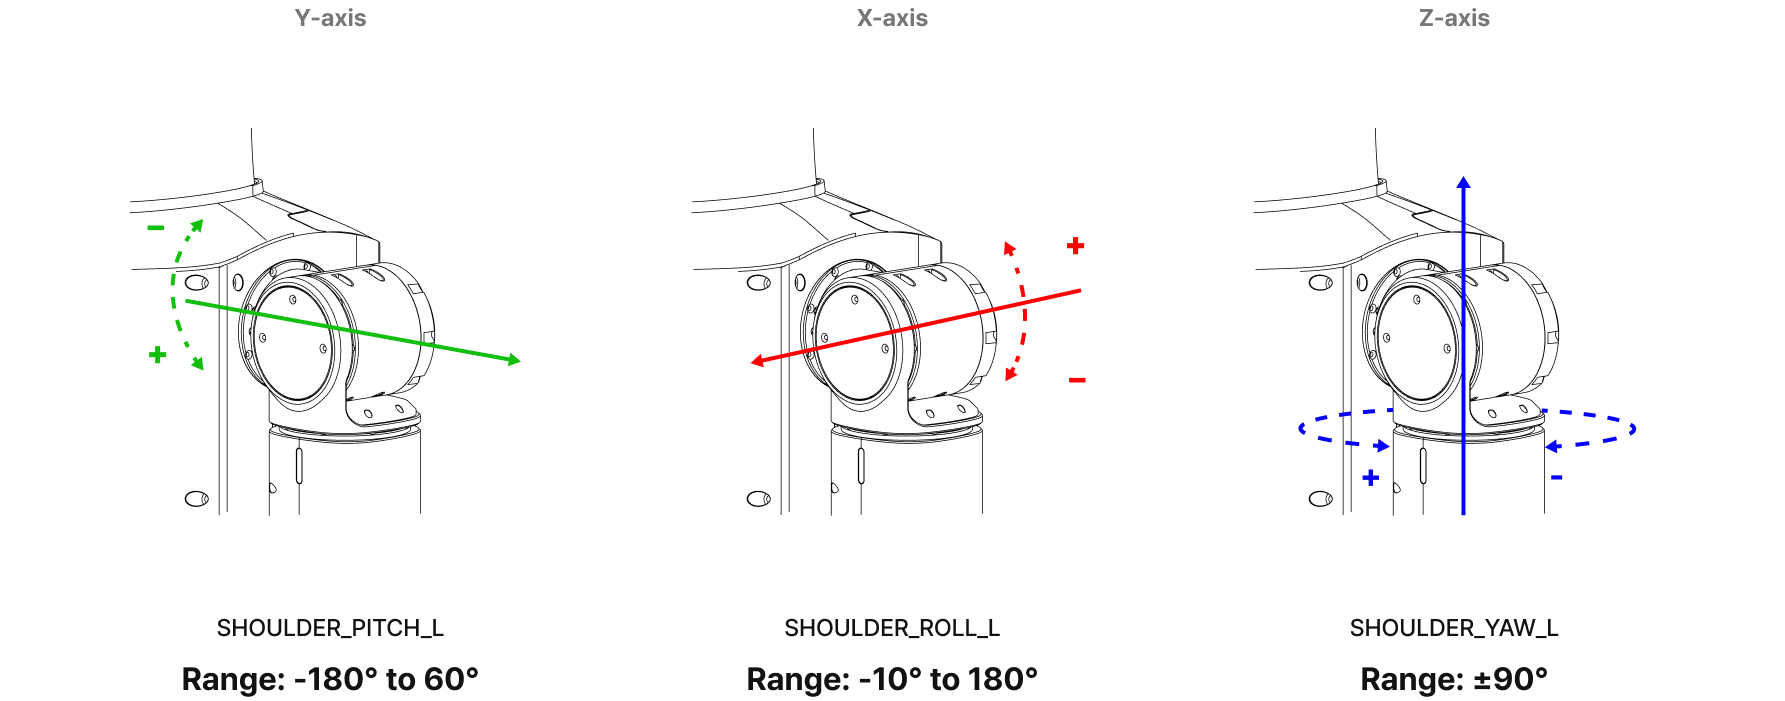
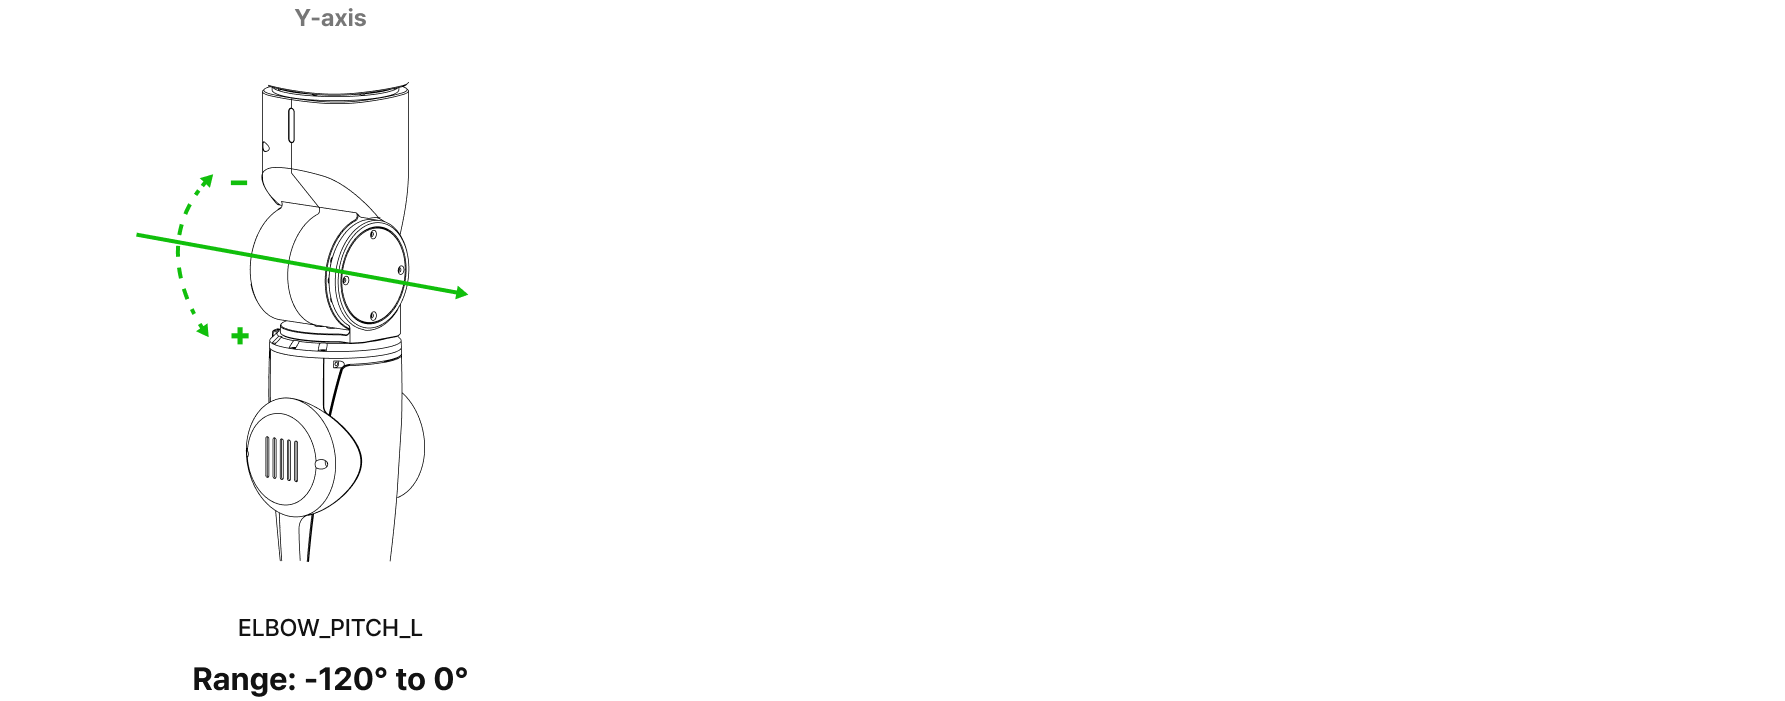
SHOULDER_PITCH_L | Y | -180 | 60 |
SHOULDER_ROLL_L | X | -10 | 180 |
SHOULDER_YAW_L | Z | -90 | 90 |
ELBOW_PITCH_L | Y | -120 | 0 |
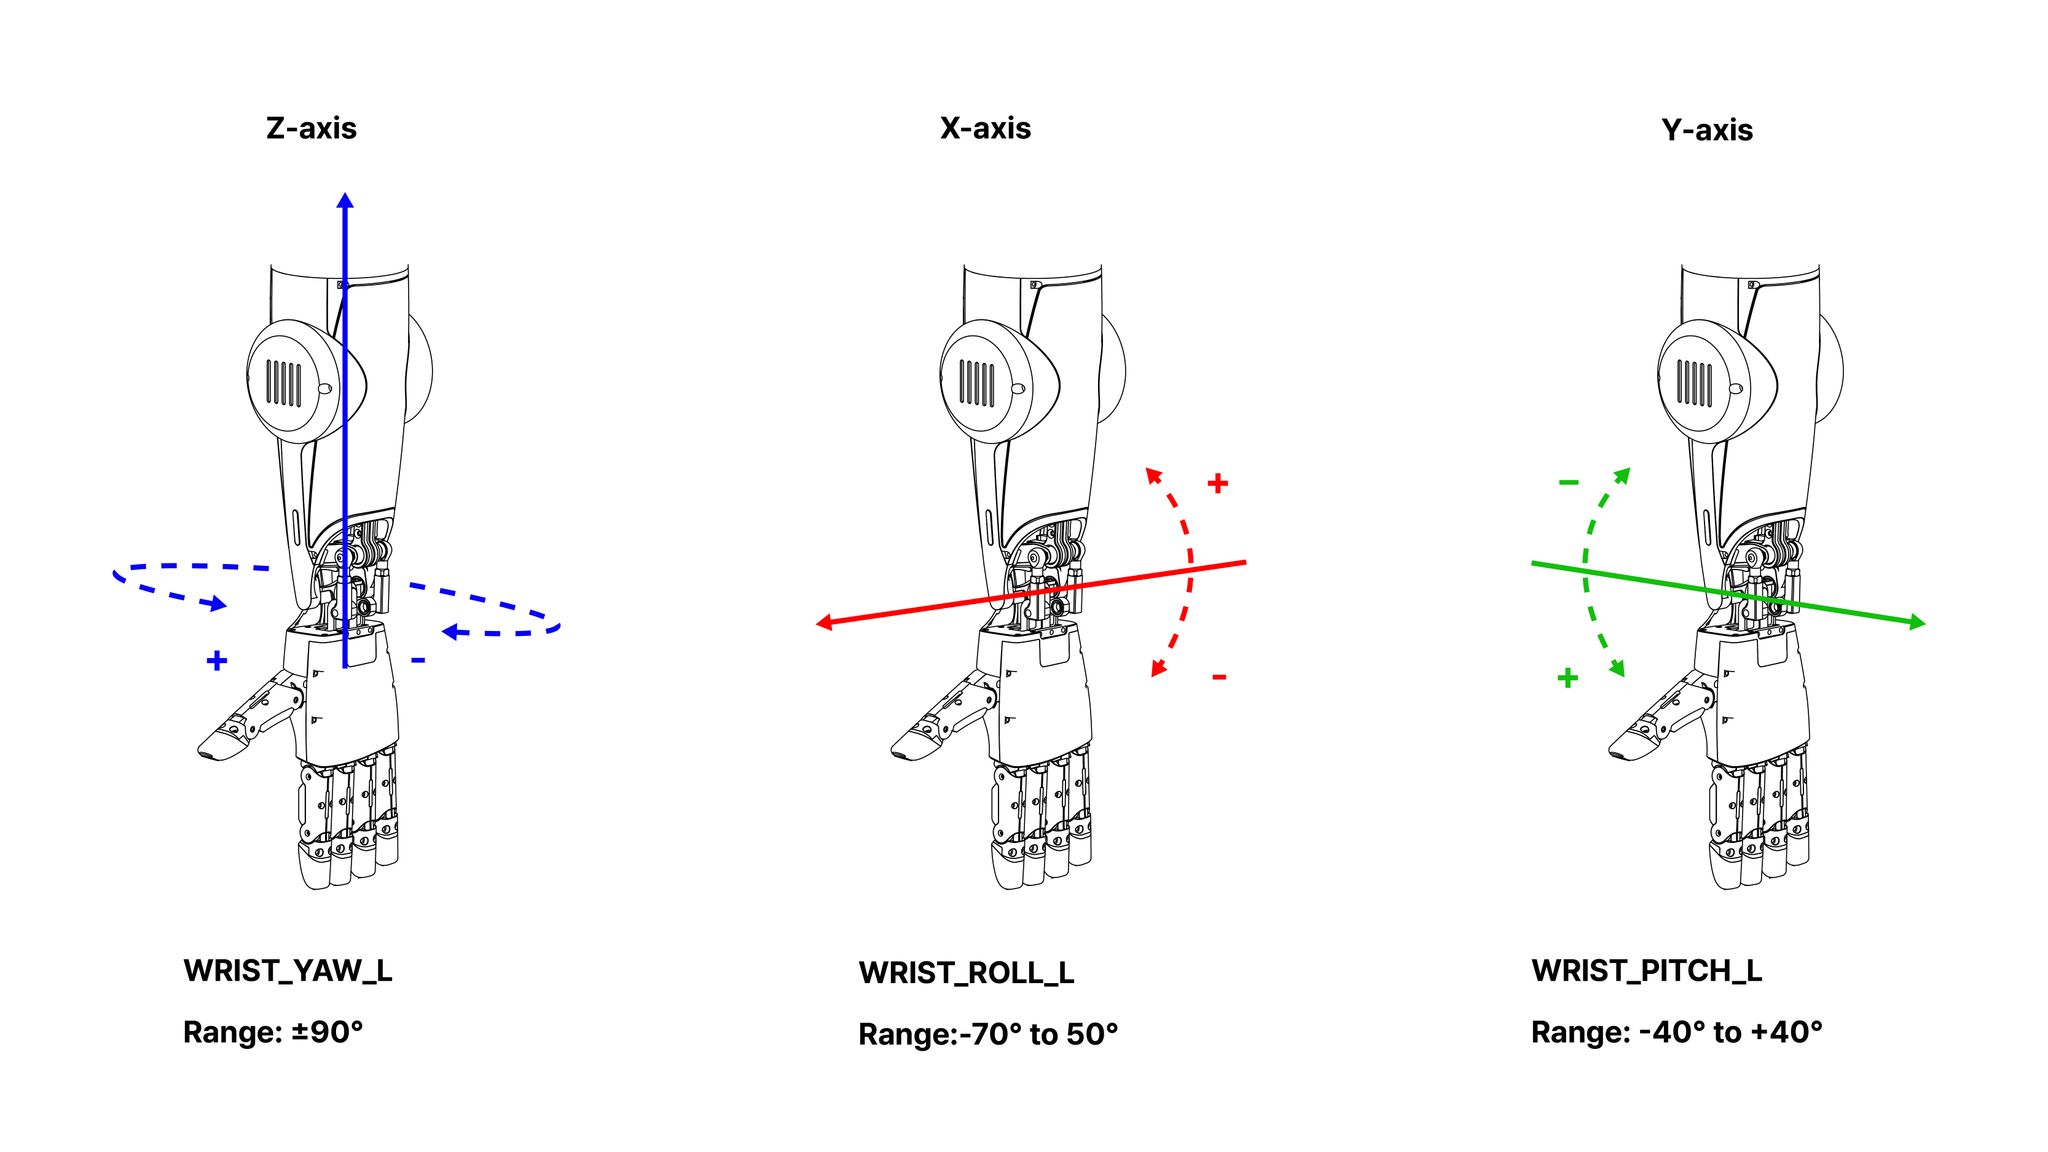
WRIST_YAW_L | Z | -90 | 90 |
WRIST_ROLL_L | X | See the WRIST table for values by wrist variant | |
WRIST_PITCH_L | Y | See the WRIST table for values by wrist variant | |
RIGHT ARM
JOINT | AXIS | MIN (°) | MAX (°) |
|---|---|---|---|
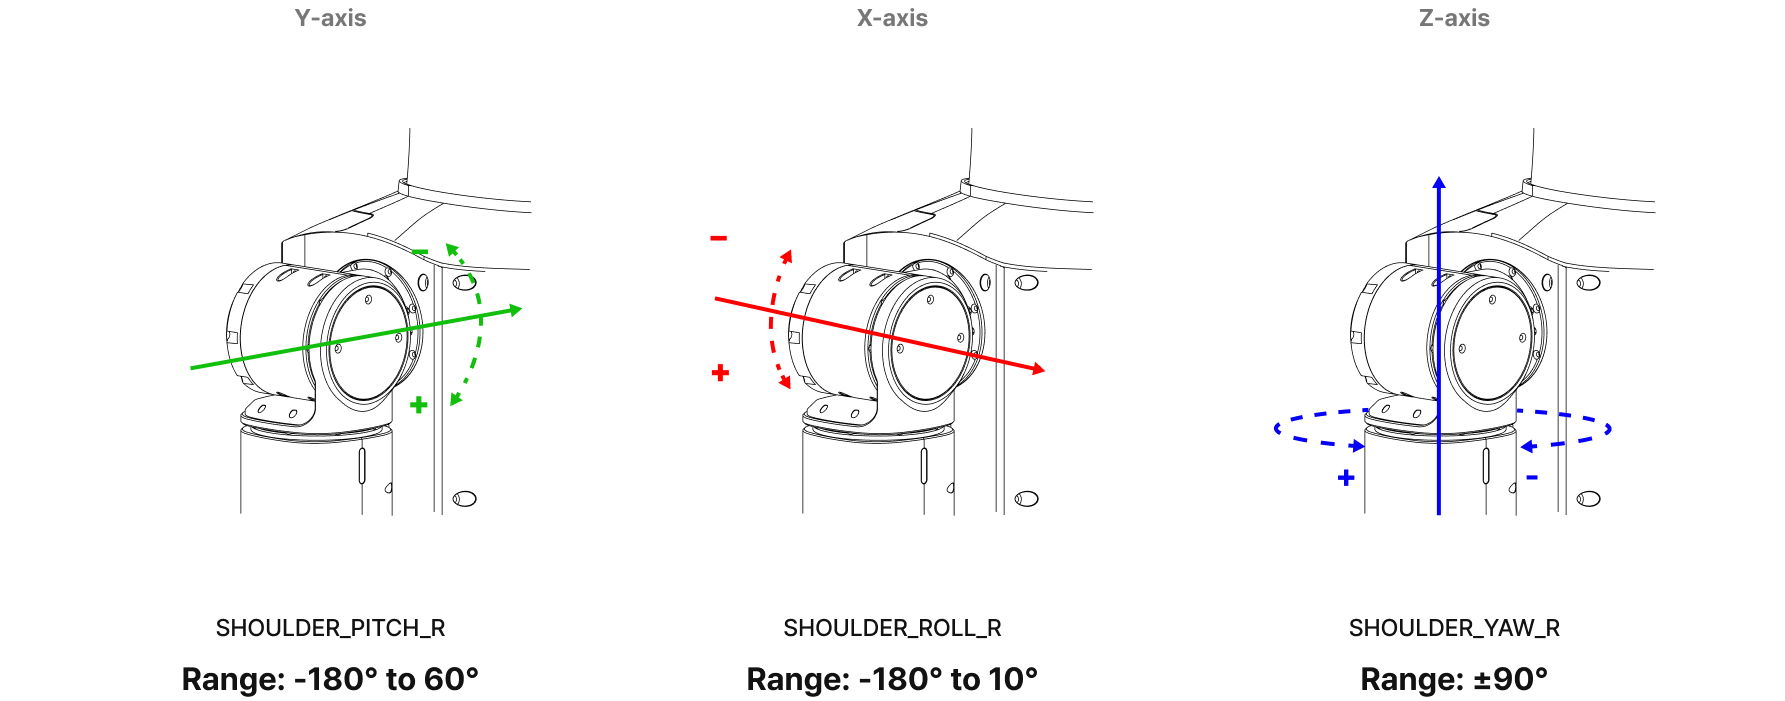
SHOULDER_PITCH_R | Y | -180 | 60 |
SHOULDER_ROLL_R | X | -180 | 10 |
SHOULDER_YAW_R | Z | -90 | 90 |
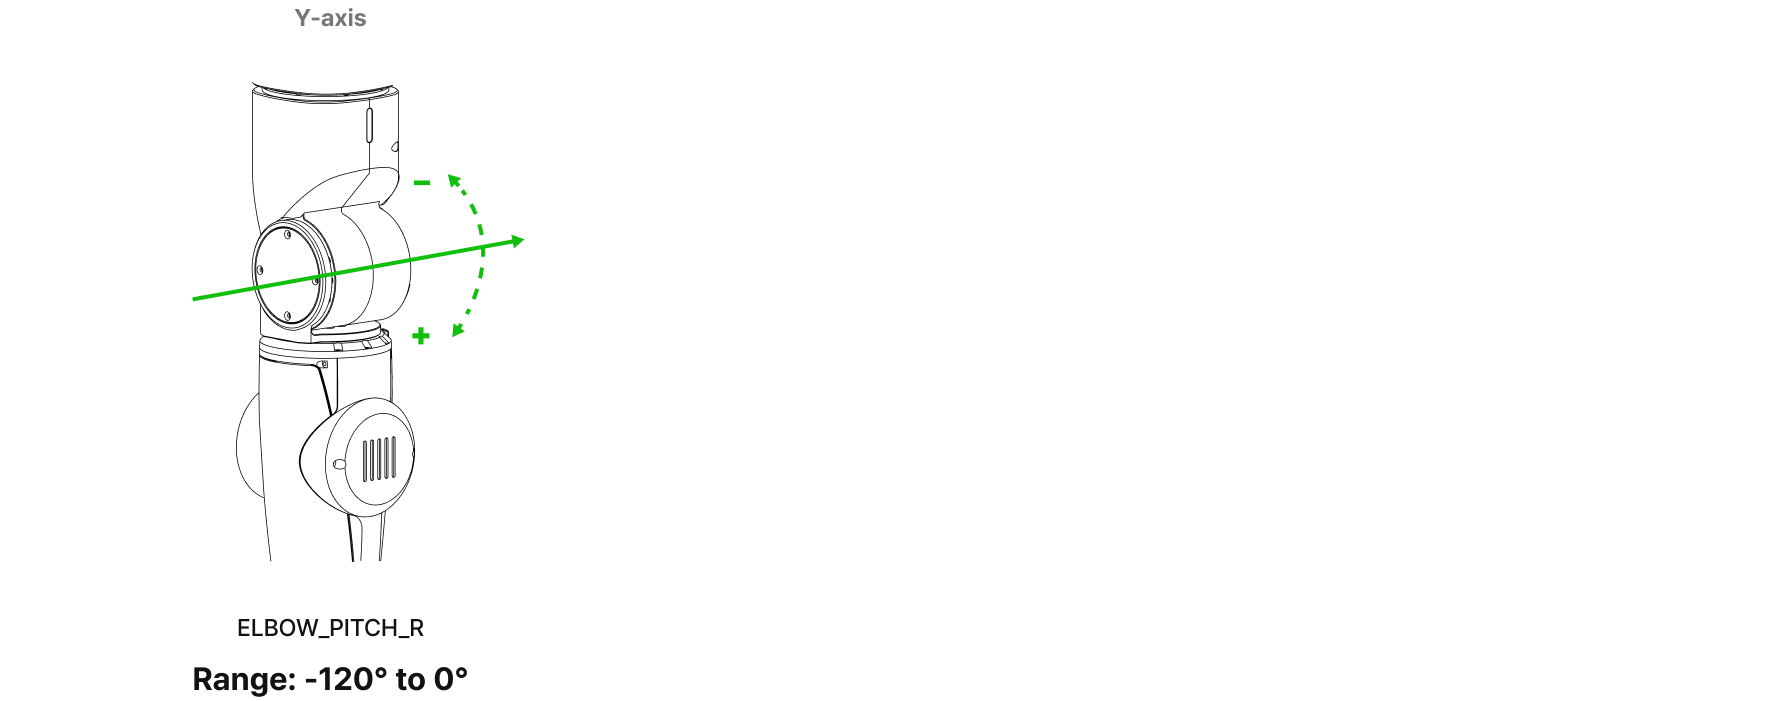
ELBOW_PITCH_R | Y | -120 | 0 |
WRIST_YAW_R | Z | -90 | 90 |
WRIST_ROLL_R | X | See the WRIST table for values by wrist variant | |
WRIST_PITCH_R | Y | See the WRIST table for values by wrist variant | |
WRIST (wrist roll / pitch by variant)
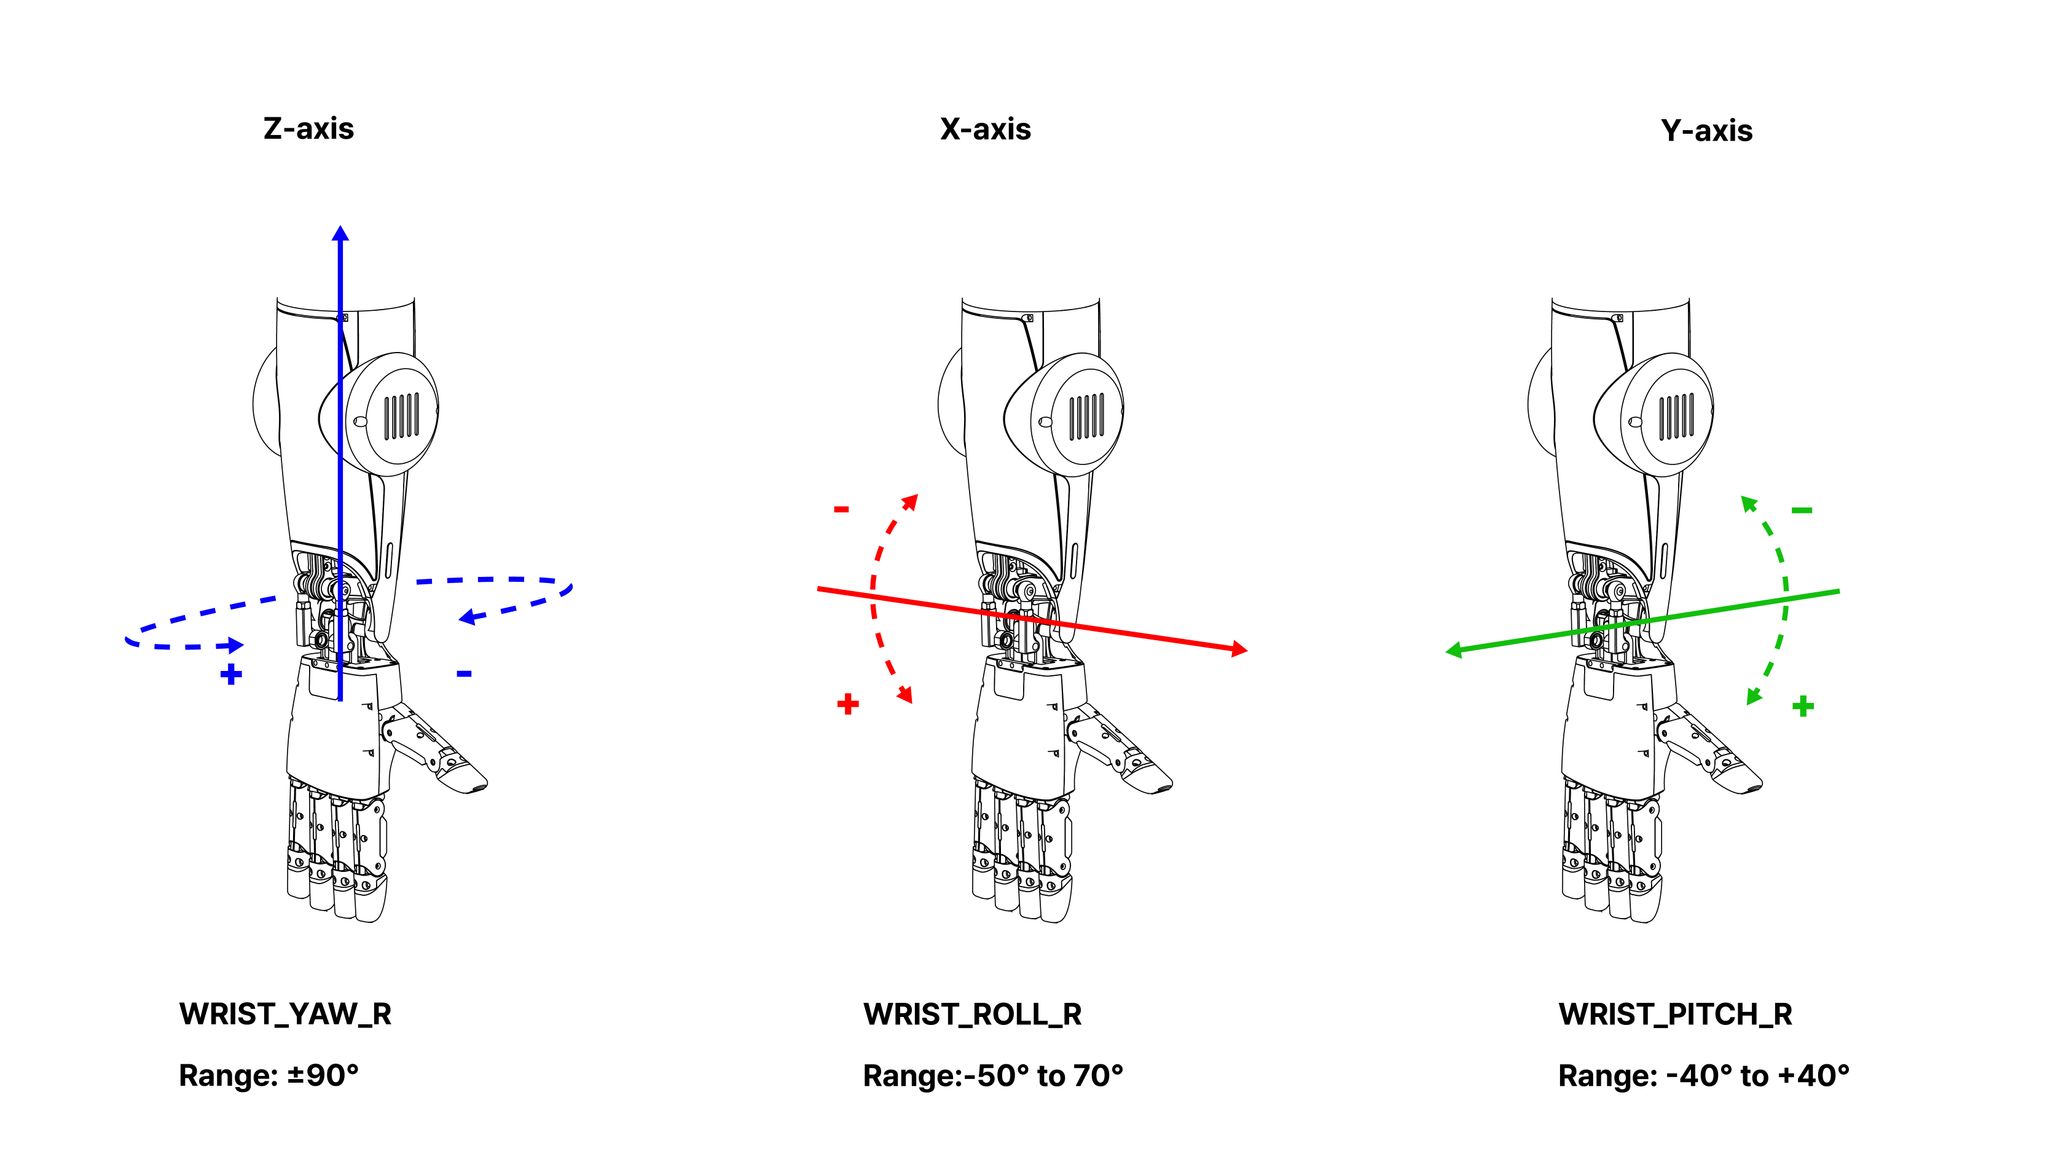
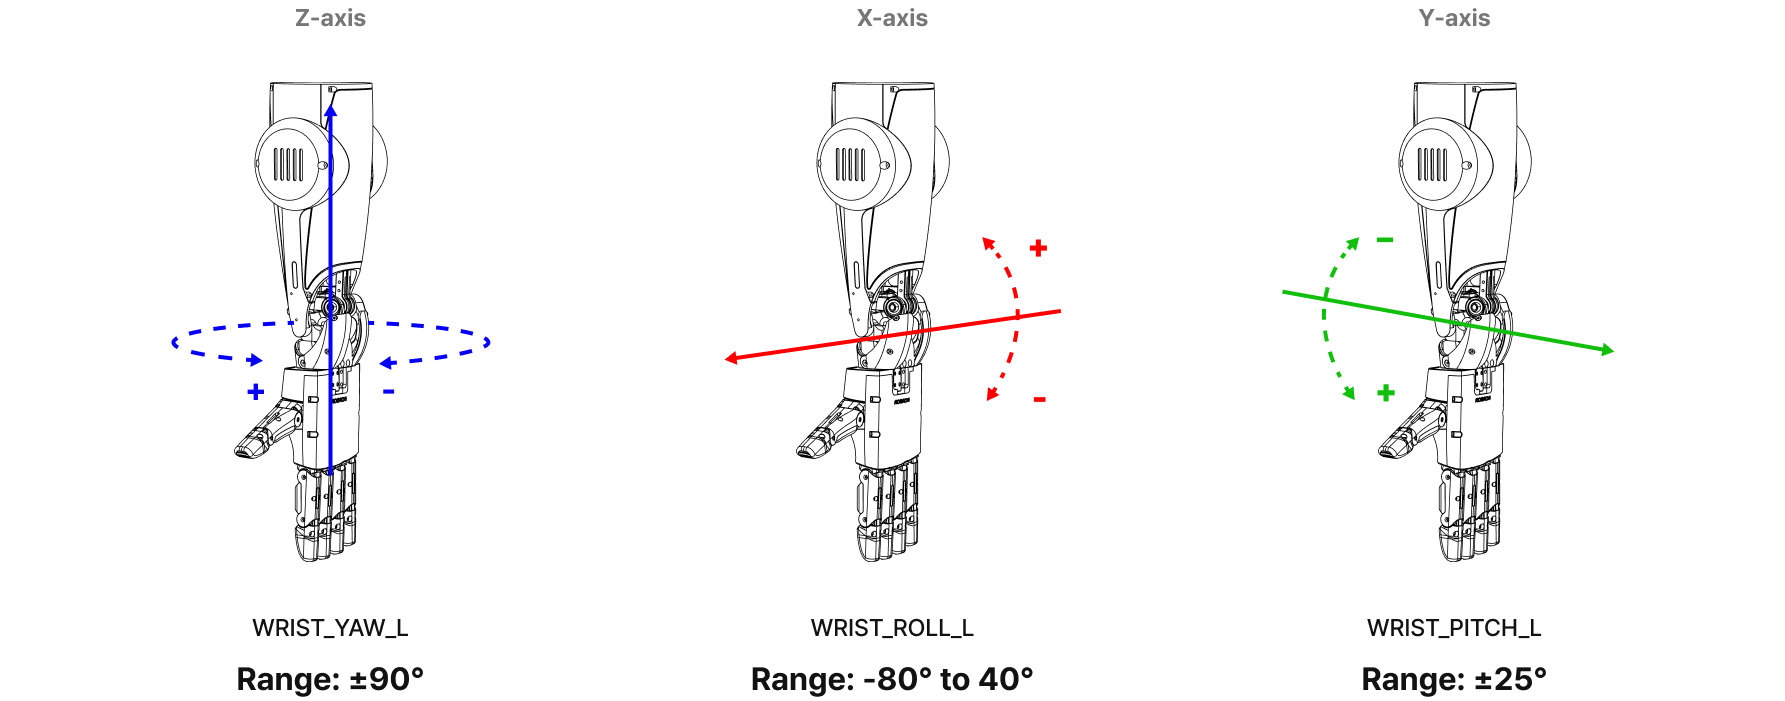
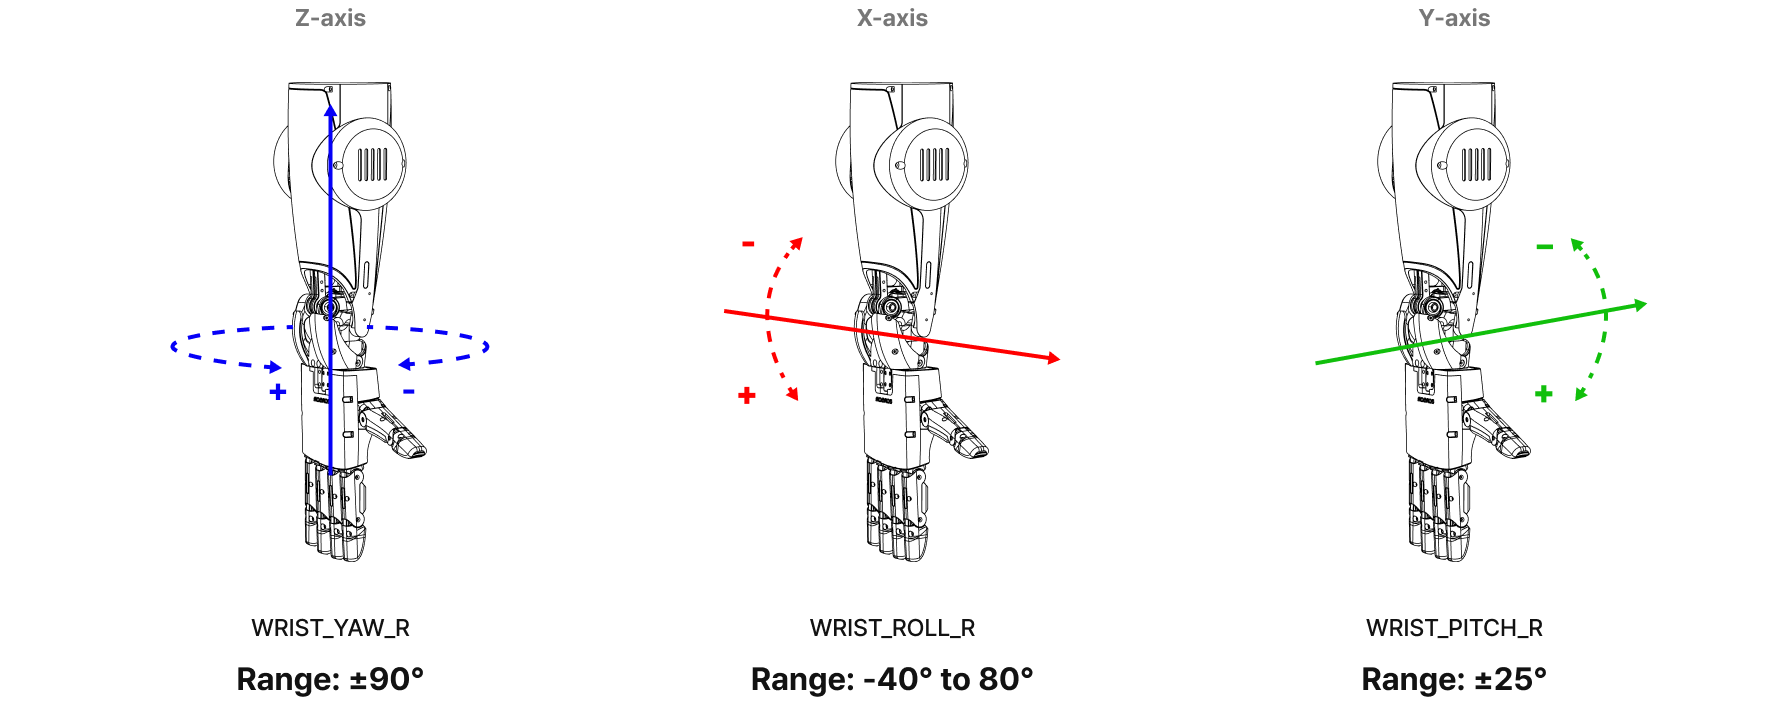
The wrist roll / pitch range of motion depends on the wrist variant (wrist_version). WRIST_YAW is -90 / +90 for both variants.
JOINT | AXIS | v1 MIN / MAX (°) | v2 MIN / MAX (°) |
|---|---|---|---|
WRIST_ROLL_L | X | -70 / +50 | -80 / +40 |
WRIST_ROLL_R | X | -50 / +70 | -40 / +80 |
WRIST_PITCH_L | Y | -40 / +40 | -25 / +25 |
WRIST_PITCH_R | Y | -40 / +40 | -25 / +25 |
Wrist v1
Wrist v2
Specs (DoF)
Hardware variants — From 2.1.1, the wrist and the ankle each come in two variants, v1 and v2. The wrist range of motion differs by variant. Check the robot’s variant in Web Viewer › Config under
description.common.wrist_version/description.common.ankle_version. Both values must match the actual hardware. Ankle v2 is a reinforced foot and has the same range of motion as v1.
1. Degree of Freedom
Total 31 DoFs (excluding hands): neck 2, waist 3, legs 6 × 2 (hip 3, knee 1, ankle 2), arms 7 × 2 (shoulder 3, elbow 1, wrist 3)
The waist, ankles, and wrists use parallel-link mechanisms, so their roll / pitch axes are mechanically coupled. Each listed range applies when the other coupled axis is at 0°.
2. Axis Convention
All joint axes are given with respect to the following fixed axes in the upright standing pose.
Front = X, Left = Y, Top = Z
3. Joint Range of Motion
NECK
JOINT | AXIS | MIN (°) | MAX (°) |
|---|---|---|---|
NECK_YAW | Z | -70 | 70 |
NECK_PITCH | Y | -30 | 30 |
WAIST
JOINT | AXIS | MIN (°) | MAX (°) |
|---|---|---|---|
WAIST_YAW | Z | -90 | 90 |
WAIST_ROLL | X | -18 | 18 |
WAIST_PITCH | Y | -50 | 16.5 |
LEFT LEG
JOINT | AXIS | MIN (°) | MAX (°) |
|---|---|---|---|
HIP_PITCH_L | Y | -118 | 30 |
HIP_ROLL_L | X | -19 | 135 |
HIP_YAW_L | Z | -90 | 90 |
KNEE_PITCH_L | Y | 0 | 131 |
ANKLE_PITCH_L | Y | -42 | 41 |
ANKLE_ROLL_L | X | -20 | 20 |
Hip
Ankle v1 | Ankle v2 |
|---|---|
| |
RIGHT LEG
JOINT | AXIS | MIN (°) | MAX (°) |
|---|---|---|---|
HIP_PITCH_R | Y | -118 | 30 |
HIP_ROLL_R | X | -135 | 19 |
HIP_YAW_R | Z | -90 | 90 |
KNEE_PITCH_R | Y | 0 | 131 |
ANKLE_PITCH_R | Y | -42 | 41 |
ANKLE_ROLL_R | X | -20 | 20 |
Hip
Ankle v1 | Ankle v2 |
|---|---|
| |
LEFT ARM
JOINT | AXIS | MIN (°) | MAX (°) |
|---|---|---|---|
SHOULDER_PITCH_L | Y | -180 | 60 |
SHOULDER_ROLL_L | X | -10 | 180 |
SHOULDER_YAW_L | Z | -90 | 90 |
ELBOW_PITCH_L | Y | -120 | 0 |
WRIST_YAW_L | Z | -90 | 90 |
WRIST_ROLL_L | X | See the WRIST table for values by wrist variant | |
WRIST_PITCH_L | Y | See the WRIST table for values by wrist variant | |
RIGHT ARM
JOINT | AXIS | MIN (°) | MAX (°) |
|---|---|---|---|
SHOULDER_PITCH_R | Y | -180 | 60 |
SHOULDER_ROLL_R | X | -180 | 10 |
SHOULDER_YAW_R | Z | -90 | 90 |
ELBOW_PITCH_R | Y | -120 | 0 |
WRIST_YAW_R | Z | -90 | 90 |
WRIST_ROLL_R | X | See the WRIST table for values by wrist variant | |
WRIST_PITCH_R | Y | See the WRIST table for values by wrist variant | |
WRIST (wrist roll / pitch by variant)
The wrist roll / pitch range of motion depends on the wrist variant (wrist_version). WRIST_YAW is -90 / +90 for both variants.
JOINT | AXIS | v1 MIN / MAX (°) | v2 MIN / MAX (°) |
|---|---|---|---|
WRIST_ROLL_L | X | -70 / +50 | -80 / +40 |
WRIST_ROLL_R | X | -50 / +70 | -40 / +80 |
WRIST_PITCH_L | Y | -40 / +40 | -25 / +25 |
WRIST_PITCH_R | Y | -40 / +40 | -25 / +25 |
Wrist v1
Wrist v2